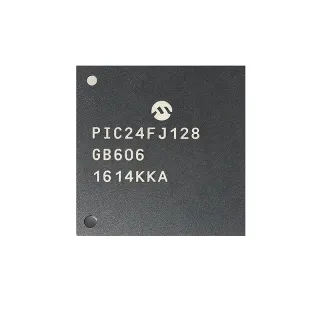
PIC24EP128MC206-E/MR - 16-Bit 60MIPS 128KB Flash Motor MCU | Microchip
料号: PIC24EP128MC206-E/MR ✓ 量产中| 数量 | 单价 | 小计 |
|---|---|---|
| 1 | $7.85 | $7.85 |
| 10 | $6.91 | $69.10 |
| 100 | $5.83 | $583.00 |
| 500 | $4.96 | $2,480.00 |
| 1,000 | $4.22 | $4,220.00 |
PIC24EP128MC206-E/MR 概述
A 16-bit motor-control microcontroller is a specialized MCU that combines a 16-bit CPU core, deterministic PWM generators, and analog peripherals optimized for closed-loop control of BLDC, PMSM, ACIM, and stepper motors. In the broader taxonomy, it sits within microcontroller (MCU) -> 16-bit MCU -> digital signal controller (DSC) -> motor-control IC. The "EP" suffix denotes enhanced peripherals including high-speed PWM, quadrature encoder interfaces, and on-chip operational amplifiers that eliminate external analog signal conditioning.
Key features include 60 MIPS execution (16-bit modified-Harvard core with DSP engine), 128 KB self-programmable Flash (43K x 24), 16 KB SRAM, six 16-bit PWM channels with dedicated time bases, dual analog comparators, three on-chip operational amplifiers (10 MHz GBW), a 12-bit 1.1 Msps ADC with up to 16 input channels, and four UART/SPI/I2C peripherals. The 9x9 mm 64-pin VQFN package provides an exposed thermal pad for improved power dissipation.
Architecturally, the device uses Microchip's PIC24E core with a 16-bit data path, hardware multiply/divide, dual-port SRAM, and a peripheral engine supporting motor-control PWM with 7.14 ns resolution. The integrated op-amps can directly sense motor phase currents, reducing BOM and PCB area, while the high-speed ADC synchronizes with PWM for precise current sampling.
Typical applications include automotive HVAC blowers, electric water/oil pumps, BLDC and PMSM motor drives, ceiling and appliance fans, e-bike controllers, robotics actuators, and drone propulsion ESCs. The AEC-Q100 Grade 0 (-40C to +150C) rating supports underhood automotive deployments.
Design consideration: route the exposed pad (EP) to a continuous ground plane with at least 16 thermal vias for production reliability, and keep analog op-amp outputs short and isolated from PWM switching traces to prevent noise coupling into current-sense feedback.
This page synthesizes distributor pricing, drop-in alternatives within the PIC24EP family, application-specific companion ICs, and PCB layout notes that complement (but do not replace) the manufacturer datasheet and family reference manual.
直接替换替代料: PIC24EP128MC206-E/MR ——相同封装,引脚兼容。需要 PCB 改动的不同封装料号已排除。
本系列中的变体
可与以下型号直接替换的同系列型号: PIC24EP128MC206-E/MR (相同外形与封装尺寸) ——差异在于 Operating Temperature, Package, ADC, Core Architecture, Maximum CPU Speed.
快速对比工具——选择替代料号进行并排对比:
PIC24EP256MC206-I/MR
✅ 直接替换 ⚠️ 规格未核验✓ 有现货
$6.39 / 个
查看数据手册 →PIC24EP64MC206-E/MR
✅ 直接替换 ⚠️ 规格未核验✓ 有现货
$2.86 / 个
查看数据手册 →PIC24EP128MC206-I/MR
✅ 直接替换 ⚠️ 规格未核验✓ 有现货
$4.77 / 个
查看数据手册 →PIC24EP128MC204-E/MV
✅ 直接替换✓ 有现货
$2.61 / 个
查看数据手册 →DSPIC33EP128MC206-E/MR
✅ 直接替换✓ 有现货
$3.28 / 个
查看数据手册 →PIC24EP128MC206-E/PT
✅ 直接替换✓ 有现货
$5.45 / 个
查看数据手册 →PIC24EP128MC206-E/MR 最大额定值与电气特性
| Core | PIC24E 16-bit dsPIC33/PIC24E DSC core |
| CPU Speed | 60 MIPS (70 MIPS instruction throughput) |
| Program Flash | 128 KB (43K x 24) |
| SRAM | 16 KB |
| Operating Voltage (Vdd) | 3.0 V to 3.6 V |
| 工作温度 | -40C to +125C (extended) |
| PWM Channels | 6 x 16-bit with 7.14 ns resolution |
| On-Chip Op-Amps | 3 x 10 MHz GBW |
| ADC | 12-bit, up to 16 channels, 1.1 Msps |
| Analog Comparators | 2 |
| Quadrature Encoder Interface (QEI) | Yes |
| Communication Peripherals | 4 x UART/SPI/I2C (configurable) |
| Timers | 9 x 16-bit / 32-bit |
| DMA Channels | 8 |
| 封装 | 64-pin VQFN (MR) 9x9 mm with exposed pad |
| 安装类型 | Surface Mount |
| AEC-Q100 | Qualified (automotive Grade 0 variant family) |
| RoHS 状态 | Compliant |
PIC24EP128MC206-E/MR 引脚配置
| 引脚 1 | RP15/RB15 — Remappable I/O / PWM fault |
| 引脚 2 | RP14/RB14 — Remappable I/O |
| 引脚 3 | RP13/RB13 — Remappable I/O |
| 引脚 4 | RP12/RB12 — Remappable I/O |
| 引脚 5 | RP11/RB11 — Remappable I/O |
| 引脚 6 | RP10/RB10 — Remappable I/O |
| 引脚 7 | RP9/RB9 — Remappable I/O |
| 引脚 8 | RP8/RB8 — Remappable I/O |
| 引脚 9 | RP7/RB7 — Remappable I/O |
| 引脚 10 | RP6/RB6 — Remappable I/O |
| 引脚 11 | VDD — Core supply 3.3V |
| 引脚 12 | VSS — Ground |
| 引脚 13 | OSC1/RC12 — Crystal input or remappable I/O |
| 引脚 14 | OSC2/RC15 — Crystal output or remappable I/O |
| 引脚 15 | RP5/RB5 — Remappable I/O |
| 引脚 16 | RP4/RB4 — Remappable I/O |
| 引脚 17 | RP3/RB3 — Remappable I/O |
| 引脚 18 | RP2/RB2 — Remappable I/O |
| 引脚 19 | RP1/RB1 — Remappable I/O |
| 引脚 20 | RP0/RB0 — Remappable I/O |
| 引脚 21 | AVDD — Analog supply 3.3V |
| 引脚 22 | AVSS — Analog ground |
| 引脚 23 | AN0/RA0 — ADC input / analog I/O |
| 引脚 24 | AN1/RA1 — ADC input / analog I/O |
| 引脚 25 | AN2/RA2 — ADC input / analog I/O |
| 引脚 26 | AN3/RA3 — ADC input / analog I/O |
| 引脚 27 | AN4/RA4 — ADC input / analog I/O |
| 引脚 28 | AN5/RA5 — ADC input / analog I/O |
| 引脚 29 | VREF+/VDD — ADC voltage reference positive |
| 引脚 30 | VREF-/VSS — ADC voltage reference negative |
| 引脚 31 | AN6/RA6 — ADC input / analog I/O |
| 引脚 32 | AN7/RA7 — ADC input / analog I/O |
| 引脚 33 | AN8/RB0 — ADC input / remappable I/O |
| 引脚 34 | AN9/RB1 — ADC input / remappable I/O |
| 引脚 35 | AN10/RB2 — ADC input / remappable I/O |
| 引脚 36 | AN11/RB3 — ADC input / remappable I/O |
| 引脚 37 | AN12/RB4 — ADC input / remappable I/O |
| 引脚 38 | AN13/RB5 — ADC input / remappable I/O |
| 引脚 39 | AN14/RB6 — ADC input / remappable I/O |
| 引脚 40 | AN15/RB7 — ADC input / remappable I/O |
| 引脚 41 | OPA1IN/RA8 — Op-amp 1 input / analog I/O |
| 引脚 42 | OPA1OUT/RA9 — Op-amp 1 output / analog I/O |
| 引脚 43 | OPA2IN/RA10 — Op-amp 2 input / analog I/O |
| 引脚 44 | OPA2OUT/RA11 — Op-amp 2 output / analog I/O |
| 引脚 45 | OPA3IN/RA12 — Op-amp 3 input / analog I/O |
| 引脚 46 | OPA3OUT/RA13 — Op-amp 3 output / analog I/O |
| 引脚 47 | PWM1H/RE0 — PWM channel 1 high side output |
| 引脚 48 | PWM1L/RE1 — PWM channel 1 low side output |
| 引脚 49 | PWM2H/RE2 — PWM channel 2 high side output |
| 引脚 50 | PWM2L/RE3 — PWM channel 2 low side output |
| 引脚 51 | PWM3H/RE4 — PWM channel 3 high side output |
| 引脚 52 | PWM3L/RE5 — PWM channel 3 low side output |
| 引脚 53 | FLT32/RE6 — PWM fault input |
| 引脚 54 | FLT33/RE7 — PWM fault input |
| 引脚 55 | QEA/RD0 — Quadrature encoder A / remappable I/O |
| 引脚 56 | QEB/RD1 — Quadrature encoder B / remappable I/O |
| 引脚 57 | INDX/RD2 — Quadrature index / remappable I/O |
| 引脚 58 | HOME/RD3 — Home input / remappable I/O |
| 引脚 59 | MCLR — Master clear reset (active low) |
| 引脚 60 | PGED2/RA0 — Programming data / remappable I/O |
| 引脚 61 | PGEC2/RA1 — Programming clock / remappable I/O |
| 引脚 62 | VDD — I/O supply 3.3V |
| 引脚 63 | VSS — Ground |
| 引脚 64 | EP — Exposed thermal pad (connect to GND) |
典型应用
PIC24EP128MC206-E/MR 适用于 6 应用s: Automotive HVAC Blower Motor Control, Brushless DC (BLDC) Motor Drive for Pumps and Fans, PMSM / Servo Motor Controller for Robotics, Electric Water / Oil Pump Controller, Drone / UAV Electronic Speed Controller (ESC), Industrial Variable-Frequency Drive (VFD) Control Card.
Automotive HVAC Blower Motor Control
The PIC24EP128MC206-E/MR is a strong fit for automotive HVAC blower motor control because its 60 MIPS PIC24E core runs field-oriented control (FOC) algorithms in real time, while the three on-chip 10 MHz op-amps directly sense shunt-based phase currents without external analog signal conditioning. The six 16-bit PWM channels (7.14 ns edge resolution) drive a three-phase BLDC gate driver with center-aligned switching to minimize EMI in cabin audio bands. AEC-Q100 qualification with the -E extended -40C to +125C grade supports underhood air-handler locations. Design tip: route PWM outputs symmetrically to the gate driver, keep op-amp feedback traces short (<10 mm), and use a 4-layer PCB with a continuous ground pour under the QFN exposed pad tied to GND with at least 16 thermal vias.
推荐
Brushless DC (BLDC) Motor Drive for Pumps and Fans
For 24-48V BLDC pumps and fans, the PIC24EP128MC206-E/MR provides 128 KB Flash for sinusoidal commutation lookup tables, 16 KB SRAM for current-loop state variables, and a 12-bit 1.1 Msps ADC synchronized to PWM edges for precise current sampling. The integrated quadrature encoder interface (QEI) accepts Hall or encoder feedback for sensorless trapezoidal or sensored FOC control. Compared with 8-bit MCUs, the 60 MIPS throughput eliminates CPU bottlenecks at 30 kHz PWM frequencies. Place a 0.1 uF ceramic decoupling capacitor within 2 mm of each Vdd pin and keep the analog AGND and digital GND separated until they meet at the exposed pad for clean current-sense measurements.
推荐
PMSM / Servo Motor Controller for Robotics
The PIC24EP128MC206-E/MR supports PMSM servo applications where the DSP engine executes field-oriented control (FOC) in under 10 us per cycle. The hardware QEI decodes incremental A/B encoder signals up to 5 MHz, while the on-chip op-amps amplify low-voltage shunt signals before ADC sampling for torque-loop control. The 16 KB SRAM holds Clarke/Park transform state and SVPWM duty commands. With the same 64-pin VQFN footprint and same peripherals, design teams can migrate from prototype to production without changing schematics. For robotics, ensure the PCB layout follows 4-layer stackup with the QFN EP providing the thermal anchor for sustained motor-control compute loads.
推荐
Electric Water / Oil Pump Controller
In 12V/24V automotive electric water and oil pumps, the PIC24EP128MC206-E/MR's AEC-Q100 qualification, -40C to +125C operating range, and on-chip op-amps enable direct shunt-based current sensing without external components. The 60 MIPS PIC24E core closes PI speed and current loops deterministically at 20 kHz PWM. Hardware fault inputs (analog comparators and PWM fault pins) shut down the gate driver within 25 ns on overcurrent events, meeting ISO 26262 ASIL-A pump safety targets. Use 1% tolerance sense resistors rated for >2x steady-state current, and place an RC filter (100 ohm / 100 pF) on each op-amp output to attenuate switching noise before ADC sampling.
推荐
Drone / UAV Electronic Speed Controller (ESC)
Lightweight ESC designs benefit from the PIC24EP128MC206-E/MR's small 9x9 mm VQFN footprint, integrated op-amps for current sensing, and 6-PWM output that drives three-phase half-bridges at 48 kHz fast switching. With 60 MIPS throughput, fast sinusoidal commutation runs at 8-16 kHz with low loop latency for tight RPM control under varying load. The 16 KB SRAM holds timing-critical state without DMA stalls. Design tip: keep PWM traces short and impedance-controlled (50 ohm), use gate drivers with <50 ns propagation delay, and add TVS diodes on the DC bus to clamp inductive kickback. Add a back-EMF zero-cross detector using the on-chip analog comparators for sensorless startup.
推荐
Industrial Variable-Frequency Drive (VFD) Control Card
For industrial VFDs, the PIC24EP128MC206-E/MR provides 128 KB Flash for V/Hz and sensorless FOC firmware libraries, dual UART/SPI/I2C peripherals for Modbus RTU or SPI encoder feedback, and 6 PWM channels capable of driving IGBT gate drivers up to 20 kHz. The -40C to +125C extended grade handles enclosed cabinet environments. Replace legacy 8-bit MCUs with this PIC24E to add sensorless operation, dead-time compensation, and per-cycle current limiting. For VFD control cards, route analog feedback (CT/PT secondaries) through dedicated op-amp channels and add isolated gate-driver supplies (e.g., Si8271) between control and power stages.
推荐
推荐产品汇总
工程参考数据: PIC24EP128MC206-E/MR ——对比、设计指导和合规信息。
选型指南
与替代料对比
| 参数 | 本产品 | PIC24EP256MC206-I/MR | PIC24EP64MC206-E/MR | PIC24EP128MC206-I/MR | dsPIC33EP128MC206-E/MR |
|---|---|---|---|---|---|
| Package | 64-VQFN (MR) 9x9 mm with exposed pad | 64-VQFN (MR) 9x9 mm - same | 64-VQFN (MR) 9x9 mm - same | 64-VQFN (MR) 9x9 mm - same | 64-VQFN (MR) 9x9 mm - same |
| Brand | Microchip Technology | Microchip Technology | Microchip Technology | Microchip Technology | Microchip Technology |
| Core | PIC24E 16-bit | PIC24E 16-bit | PIC24E 16-bit | dsPIC33E 16-bit DSC (DSP engine) | |
| CPU Speed | 60 MIPS | 60 MIPS | 60 MIPS | 60 MIPS | |
| Flash | 128 KB | 256 KB (+100%) | 64 KB (-50%) | 128 KB (same) | 128 KB (same) |
| SRAM | 16 KB | 16 KB | 8 KB (-50%) | 16 KB | |
| Temperature Grade | -40C to +125C (E, extended) | -40C to +85C (I, industrial) | -40C to +125C (E, extended) | -40C to +85C (I, industrial) | |
| AEC-Q100 | Qualified (family) | Qualified (family) | Qualified (family) | Qualified (family) | |
| On-Chip Op-Amps | 3 x 10 MHz | 3 x 10 MHz | 3 x 10 MHz | 3 x 10 MHz | |
| PWM Channels | 6 x 16-bit | 6 x 16-bit | 6 x 16-bit | 6 x 16-bit |
关键差异点
- Triple integrated on-chip op-amps eliminate external current-sense analog (对比 PIC24EP128GP206 (no MC op-amps))
- AEC-Q100 qualified with extended -40C to +125C grade (对比 PIC24EP128GP206 industrial grade)
- Six 16-bit PWM with 7.14 ns edge resolution (对比 PIC24EP128MC204 (4 PWM channels))
设计说明
The 64-pin 9x9 mm VQFN package dissipates motor-control compute heat through the exposed thermal pad. Connect EP to a continuous ground plane on the top layer with at least 16 thermal vias (0.3 mm drill, 0.5 mm pad) to the inner ground plane. At 60 MIPS full load with sustained PWM activity, junction temperature can rise 25-35 C above ambient without a thermal via array. For underhood automotive deployments (-40C to +125C ambient), the thermal via count should be increased to 20+ vias to maintain junction below 150 C.
Route analog op-amp inputs (OPA1IN/OPA2IN/OPA3IN) and current-shunt traces directly to the shunt resistors with short (<10 mm) and symmetric differential routing. Place 100 ohm / 100 pF RC filters on op-amp outputs to attenuate PWM switching noise before ADC sampling. Keep analog ground (AVSS) and digital ground (VSS) separated until they merge at the EP ground pour. Place 0.1 uF ceramic decoupling capacitors within 2 mm of every VDD/AVDD pin and add a single 10 uF bulk capacitor near the IC supply input.
Do not float the MCLR pin - tie it to VDD through a 10 kohm pull-up resistor to avoid unintended resets. Configure unused PWM outputs as GPIO outputs driven low to prevent shoot-through in the gate driver. Verify ADC sampling is synchronized to PWM edges in PWM-trigger mode to avoid sampling during switching transients. Do not exceed the absolute maximum VDD of 3.6 V - using a 5V supply will damage the MCU. Always validate the BOR (brown-out reset) threshold setting matches the system voltage profile.
PWM outputs driving external gate drivers should use 50 ohm characteristic impedance traces and be length-matched within 5 mm between high-side and low-side pairs of the same channel to prevent timing skew. Place a series ferrite bead or 10 ohm resistor near the MCU PWM pin to dampen transmission-line ringing when driving capacitive gate loads. For QEI inputs from motor encoders, route A/B/INDEX signals as a matched differential or guarded triplet to reject common-mode motor switching noise.
合规信息
AEC-Q100 qualified per Microchip PIC24EP family qualification reports. RoHS and lead-free confirmed by Microchip product page and LCSC listing. Halogen-free status not explicitly stated - set to unknown per data authenticity rules.