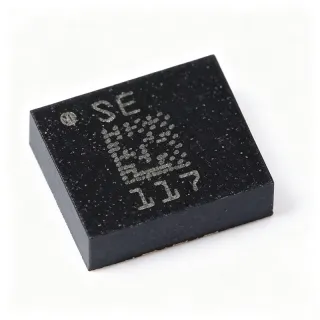
LSM6DSOXTR - 6-Axis IMU with AI ML Core | STMicroelectronics
Teilenummer: LSM6DSOXTR ✓ Aktiv| Menge | Stückpreis | Gesamt |
|---|---|---|
| 1 | $2.35 | $2,35 |
| 10 | $2.12 | $21,20 |
| 100 | $1.95 | $195,00 |
| 500 | $1.9434 | $971,70 |
| 1.000 | $1.75 | $1.750,00 |
| 3.000 | $1.58 | $4.740,00 |
LSM6DSOXTR Übersicht
An IMU (inertial measurement unit) is a motion sensor module that measures acceleration and angular velocity simultaneously. It sits at the top of the motion-sensing hierarchy - accelerometer + gyroscope + fusion logic - within the broader sensor IC family used for orientation, gesture, and activity tracking in embedded and power management systems.
Key features include accelerometer ranges up to 16 g and gyroscope ranges up to 2000 dps, an I2C and SPI digital interface, an auxiliary SPI (OIS) interface for camera optical image stabilization, and the ST FINITE state machine plus decision-tree machine learning core that offloads pattern detection from the host MCU. Always-on operation is enabled by low power modes with wakeup and activity/inactivity detection.
The MEMS sensor die is packaged with a dedicated ASIC that performs 16-bit data conversion and on-chip FIFO buffering, allowing the host to sleep while the IMU autonomously classifies motion events. The embedded AI core executes user-trained decision trees directly in-sensor, cutting system power and latency for always-on context awareness.
Typical applications include wearables and fitness trackers, smartphone screen rotation and tap detection, industrial condition monitoring, and drone/robotics attitude estimation.
Design consideration: keep the IMU away from vibration sources and board flex zones, and use I2C pull-ups appropriate for the bus speed; configure the ML core with ST's Unico/Unicleo GUI tools before deployment in firmware.
This page adds value beyond the datasheet with distributor pricing tiers, drop-in alternatives, and practical design notes synthesized from verified web data.
Drop-in-Alternativen für LSM6DSOXTR – gleiches Gehäuse, Pin-kompatibel. Bauteile mit anderem Gehäuse, die eine PCB-Überarbeitung erfordern, sind ausgeschlossen.
Varianten dieser Serie
Modelle derselben Serie, die drop-in-kompatibel sind mit LSM6DSOXTR (gleiche Bauform und Footprint) – abweichend in Package, Embedded Features, Interface, Gyroscope Full-Scale Range, Operating Temperature.
Schnellvergleichstool – Wählen Sie Alternativbauteile für den Direktvergleich:
LSM6DSOTR
✅ Drop-In✓ Auf Lager
$2.65 / Stück
Datenblatt ansehen →LSM6DSO32TR
✅ Drop-In📋 Referenzalternative (nicht im Katalog)
LSM6DSVTR
✅ Drop-In📋 Referenzalternative (nicht im Katalog)
LSM6DS3TR
✅ Drop-In✓ Auf Lager
$1.05 / Stück
Datenblatt ansehen →LSM6DSOXTR Grenzwerte & elektrische Eigenschaften
| Sensortyp | 6-axis IMU (3-axis accelerometer + 3-axis gyroscope) |
| Accelerometer Range | 2 g to 16 g (selectable) |
| Gyroscope Range | 125 dps to 2000 dps (selectable) |
| Versorgungsspannung | 1.71 V to 3.6 V |
| Current Consumption (high-performance mode) | 0.55 mA |
| Schnittstelle | I2C / SPI (3-wire and 4-wire) |
| Auxiliary Interface | Auxiliary SPI for OIS |
| Embedded Features | Machine learning core, finite state machine (FSM) |
| FIFO | On-chip FIFO buffer |
| Gehäuse | LGA-14 (2.5 mm x 3.0 mm x 0.83 mm) |
| Montageart | Surface Mount |
| Series | iNEMO LSM6D |
| RoHS-Status | Compliant |
LSM6DSOXTR lga-14 (2.5 mm x 3.0 mm x 0.83 mm) Pinbelegungsleitfaden
Pinbelegung für LSM6DSOXTR (lga-14 (2.5 mm x 3.0 mm x 0.83 mm)-Gehäuse). Pin-Nummerierung, Funktionen und Anschlussdiagramme sind im Herstellerdatenblatt definiert. Entnehmen Sie diesem den genauen Footprint und Lötrichtlinien.
Keine detaillierten Pinbelegungsdaten verfügbar für LSM6DSOXTR.
Siehe die Datenblatt für die vollständige Pin-Konfiguration.
Typische Anwendungen
LSM6DSOXTR ist geeignet für 6 Anwendungs: Wearables and Fitness Trackers, Smartphone Screen Rotation and Tap Detection, Optical Image Stabilization (OIS), Industrial Condition Monitoring, Drone and Robotics Attitude Estimation, IoT Context-Aware Devices.
Wearables and Fitness Trackers
The LSM6DSOXTR fits wearables because its always-on 0.55 mA high-performance mode and richer set of low-power modes keep motion tracking alive around the clock while preserving battery budget in a sub-100 mAh cell. The embedded machine learning core classifies activities such as walking, running, or fall events in-sensor, so the host MCU stays in sleep and overall system current drops. Its 2.5 mm x 3.0 mm LGA-14 footprint fits slim wrist-worn enclosures, and the I2C interface integrates directly with low-power MCU platforms.
Empfohlen
Smartphone Screen Rotation and Tap Detection
For smartphones and tablets, the LSM6DSOXTR provides screen orientation, tap, double-tap, and pickup detection using hardware interrupts rather than continuous polling. The accelerometer and gyroscope ODRs are configured so that INT1/INT2 fire only on recognized events, cutting host wakeups dramatically. The auxiliary SPI (OIS) interface can simultaneously serve the camera image-stabilization controller while the main I2C bus serves the application processor, consolidating two motion-sensing functions into one 6-axis device.
Empfohlen
Optical Image Stabilization (OIS)
Camera modules use the LSM6DSOXTR auxiliary SPI port in Mode 3 or Mode 4, wired directly to the lens controller, to deliver low-latency gyro data for optical image stabilization. Because the aux interface is independent of the main I2C/SPI bus, stabilization data flows continuously even while the primary host configures registers, avoiding bus contention at critical shutter moments. Gyro rates up to 2000 dps cover handshake and vibration frequencies, and high-rate ODRs give the OIS loop the bandwidth it needs.
Empfohlen
Industrial Condition Monitoring
In industrial equipment health monitoring, the LSM6DSOXTR detects abnormal vibration signatures on motors, pumps, and gearboxes. The machine learning core runs user-trained decision trees in-sensor, so vibration thresholding and anomaly flags occur without streaming raw data off-board, and the FIFO buffers bursts for later retrieval. With a 1.71 V to 3.6 V supply and 0.55 mA typical current, the sensor suits battery-powered wireless vibration nodes; 16 g full scale captures shock events on rotating machinery.
Empfohlen
Drone and Robotics Attitude Estimation
Flight controllers and robot platforms use the LSM6DSOXTR as the primary gyro/accel source for attitude estimation in complementary or Kalman filters. The 2000 dps gyroscope range covers aggressive maneuvers, and configurable output data rates up to several kHz feed filter loops with fresh samples over SPI. The low 0.55 mA high-performance draw matters for small multirotors and battery robots, and the on-chip FIFO decouples sensor timing from MCU scheduling, reducing jitter in the control loop.
Empfohlen
IoT Context-Aware Devices
Smart-home and IoT nodes leverage the LSM6DSOXTR finite state machine to detect door openings, tampering, appliance movement, or free-fall while the rest of the system sleeps. Because event classification happens in-sensor, only an interrupt line wakes the host, cutting standby current to microamp levels overall. The 1.71 V to 3.6 V rail range matches coin-cell and Li-Ion power trees, and the I2C interface integrates with any mainstream MCU family, making the sensor a standard choice for always-on IoT context awareness.
Empfohlen
Zusammenfassung der empfohlenen Produkte
Technische Referenzdaten für LSM6DSOXTR – Vergleich, Designhinweise und Compliance-Informationen.
Auswahlhilfe
Vergleich mit Alternativen
| Parameter | Dieses Produkt | LSM6DSOTR | LSM6DSO32TR | LSM6DSVTR | LSM6DS3TR |
|---|---|---|---|---|---|
| Package | LGA-14 (2.5 x 3.0 x 0.83 mm) | LGA-14 - same | LGA-14 - same | LGA-14 - same | LGA-14 - same |
| Brand | STMicroelectronics | STMicroelectronics | STMicroelectronics | STMicroelectronics | STMicroelectronics |
| Accelerometer Range | 2 g to 16 g | 2 g to 16 g | 2 g to 32 g | 2 g to 16 g | 2 g to 16 g |
| Gyroscope Range | 125 to 2000 dps | 125 to 2000 dps | 125 to 2000 dps | 125 to 4000 dps | 125 to 2000 dps |
| Supply Voltage | 1.71 V to 3.6 V | 1.71 V to 3.6 V | 1.71 V to 3.6 V | 1.71 V to 3.6 V | 1.71 V to 3.6 V |
| Machine Learning Core | Yes | No | Yes | Yes (enhanced) | No |
| Auxiliary SPI (OIS) | Yes | Yes | Yes | Yes | Yes |
Wichtigste Unterscheidungsmerkmale
- Embedded machine learning core for in-sensor classification (vs. LSM6DSOTR)
- Standard 16 g accelerometer range at lower cost (vs. LSM6DSO32TR)
- Mature, widely-documented platform (vs. LSM6DSVTR)
Designhinweise
Place 100 nF ceramic decoupling capacitors on VDD and VDDIO within 2 mm of the LGA-14 pads, plus a 10 uF bulk capacitor on the VDD rail per the ST datasheet application hints. Keep the IMU away from switching regulators, loudspeakers, and board-mount transformers, whose magnetic and mechanical vibration couples into the gyro output. Locate the sensor near the mechanical center of rotation for accurate angular-rate sensing.
For I2C operation, use 2.2 k to 4.7 k pull-ups on SDA/SCL depending on bus capacitance; 400 kHz fast mode is the practical default. For SPI, keep traces under 10 cm and add a series 33 ohm resistor on SCL to damp ringing. The auxiliary SPI (OIS) port should be routed separately from the main bus to prevent contention - never tie both interfaces active simultaneously.
Configure the machine learning core and FSM using ST's Unico/Unicleo tools and validate decision trees against logged data before hard-coding them into production firmware - register-level MLC configuration errors are the most common LSM6DSOX integration failure. Also confirm that your firmware register map matches the LSM6DSOX (not LSM6DS3) datasheet if migrating from older LSM6D parts; several register addresses differ.
Compliance-Informationen
RoHS compliant per distributor listings; REACH and halogen-free status not stated in provided data.