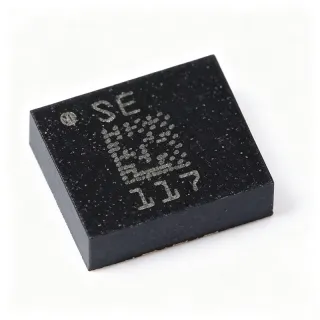
LSM6DSV80XTR - 6-Axis IMU, 80g Accel, AI Core | STMicroelectronics
Teilenummer: LSM6DSV80XTR ✓ Aktiv| Menge | Stückpreis | Gesamt |
|---|---|---|
| 1 | $7.5 | $7,50 |
| 10 | $6.75 | $67,50 |
| 100 | $6.05 | $605,00 |
| 500 | $5.4 | $2.700,00 |
| 1.000 | $4.85 | $4.850,00 |
LSM6DSV80XTR Übersicht
An IMU (Inertial Measurement Unit) is a micro-electromechanical system (MEMS) device combining multiple motion sensors - typically a 3-axis accelerometer and a 3-axis gyroscope - to measure linear acceleration and angular rate along three orthogonal axes. IMUs sit at the sensor layer of a product hierarchy: IMU -> motion sensor -> MEMS sensor -> semiconductor. They form the perception backbone for inertial navigation, gesture recognition, and context-aware applications, feeding higher-level sensor-hub processors, microcontrollers, or wireless SoCs with raw or fused motion data.
Key features include dual full-scale accelerometer ranges (±16 g and ±80 g) for capturing both subtle wrist motion and high-impact events such as falls or sport collisions, a wide ±125/±250/±500/±1000/±2000/±4000 dps gyroscope range, an embedded machine-learning core for on-device classification, and a sensor-fusion low-power (SFLP) engine that outputs quaternions and Euler angles at low µA cost. Communication is provided over I²C, I³C, and auxiliary SPI interfaces, and an integrated temperature sensor aids drift compensation.
The LSM6DSV80XTR is built on ST's proprietary THELMA MEMS process and a 130 nm mixed-signal CMOS ASIC, co-packaged in a single LGA. The dual-structure accelerometer (a high-g and a low-g transducer sharing the same sense axis) is what differentiates this part from earlier LSM6DS family members: it preserves fine resolution at low g while still capturing peak accelerations above the standard 16 g ceiling.
Typical applications include sport wearables (impact detection in boxing, running gait analysis), wristbands, AR/VR controllers, fall-detection pendants for elderly care, and personal trackers. For each use case, the relevant specification is the high-g full scale combined with the embedded ML core.
When designing with the LSM6DSV80XTR, follow ST's reference schematic exactly: a 100 nF decoupling cap on VDD plus a 10 µF bulk on VDDIO, clean ground return under the LGA thermal/exposed pad, and short traces to the host MCU. Verify I3C compatibility before substituting an I²C-only MCU.
This page synthesizes distributor pricing, drop-in replacements, and practical design notes not consolidated in the manufacturer datasheet, including a same-package alternative comparison that DigiKey and Mouser product pages do not show.
Drop-in-Alternativen für LSM6DSV80XTR – gleiches Gehäuse, Pin-kompatibel. Bauteile mit anderem Gehäuse, die eine PCB-Überarbeitung erfordern, sind ausgeschlossen.
Varianten dieser Serie
Modelle derselben Serie, die drop-in-kompatibel sind mit LSM6DSV80XTR (gleiche Bauform und Footprint) – abweichend in Embedded Features, Gyroscope Full Scale, Operating Temperature, Package, Sensor Type.
Schnellvergleichstool – Wählen Sie Alternativbauteile für den Direktvergleich:
LSM6DSV80X
✅ Drop-In📋 Referenzalternative (nicht im Katalog)
LSM6DSO32XTR
✅ Drop-In✓ Auf Lager
$3.2 / Stück
Datenblatt ansehen →LSM6DSO32XTR
✅ Drop-In✓ Auf Lager
$3.2 / Stück
Datenblatt ansehen →LSM6DSO32XTR
✅ Drop-In ⚠️ Spezifikationen ungeprüft✓ Auf Lager
$3.2 / Stück
Datenblatt ansehen →LSM6DSV80XTR Grenzwerte & elektrische Eigenschaften
| Sensortyp | Accelerometer + Gyroscope, 6-axis IMU |
| Number of Axes | 6 (X, Y, Z) |
| Output Interface | I2C, I3C, SPI |
| Accelerometer Full Scale (high-g) | ±80 g |
| Gyroscope Full Scale | ±4000 dps |
| Versorgungsspannung | 1.71 V to 3.6 V |
| Supply Current (low-power mode) | 2.9 µA |
| Betriebstemperatur | -40 °C to +85 °C |
| Gehäuse | LGA-14 (2.5 x 3 mm) |
| Embedded Features | Machine Learning Core, Sensor Fusion Low-Power (SFLP) Engine |
| Temperature Sensor | Integrated |
| Montageart | Surface Mount |
| RoHS-Status | Compliant |
| Secondary Accel Full Scale | ±16 g |
LSM6DSV80XTR Pin-Konfiguration
| Pin 1 | VDD — Core power supply, 1.71 V to 3.6 V |
| Pin 2 | GND — Ground |
| Pin 3 | VDDIO — I/O supply voltage |
| Pin 4 | SCL — I2C/I3C clock |
| Pin 5 | SDA — I2C/I3C data |
| Pin 6 | CS — SPI chip select |
| Pin 7 | SPC — SPI clock |
| Pin 8 | SDI — SPI data input |
| Pin 9 | SDO — SPI data output |
| Pin 10 | INT1 — Interrupt 1 |
| Pin 11 | INT2 — Interrupt 2 |
| Pin 12 | RES — Reserved / NC |
| Pin 13 | GND — Ground |
| Pin 14 | GND — Ground (thermal pad) |
Typische Anwendungen
LSM6DSV80XTR ist geeignet für 6 Anwendungs: Sport Impact Detection, Fall Detection Wearables, AR/VR Controller IMU, Running Gait Analysis, Industrial Vibration Monitoring, Personal Trackers and Beacons.
Sport Impact Detection
The LSM6DSV80XTR's second 80 g accelerometer structure is purpose-built for capturing high-intensity impacts in contact sports such as boxing, kickboxing, and football. With 16 g low-g and 80 g high-g full-scale sensing running in parallel, the IMU can simultaneously track subtle wrist kinematics during a punch and the peak deceleration of a glove impact, preserving low-g resolution that single-missile compressors would otherwise clip. The embedded machine-learning core can classify hit severity on-device at low µA cost, eliminating continuous high-rate streaming to a host MCU.
Empfohlen
Fall Detection Wearables
For elderly-care pendants and wristbands, the LSM6DSV80XTR's 80 g full scale is essential: typical fall events generate peak accelerations of 8-15 g but with transient spikes above 60 g during shoulder impact. The dedicated high-g path captures those transients without saturating, while the low-g path drives the always-on posture-classification ML core. Operating at 2.9 µA in low-power mode, the IMU supports multi-day battery life on small coin cells, and the I3C interface minimizes wake-up overhead when reporting events.
Empfohlen
AR/VR Controller IMU
In AR/VR controllers, the LSM6DSV80XTR delivers ±4000 dps gyroscope dynamic range combined with low-g accelerometer precision for sub-degree orientation tracking at high angular velocities such as fast swings. The sensor-fusion low-power (SFLP) engine outputs quaternions directly, offloading the host application processor and reducing end-to-end latency. The 14-pin LGA footprint suits space-constrained controller PCBs, and I3C supports up to 12.5 MHz data rates for high-ODR motion streaming.
Empfohlen
Running Gait Analysis
Foot-strike analysis in running wearables requires capturing high-g heel-strike transients alongside low-g cadence data. The LSM6DSV80XTR's dual 16 g / 80 g accelerometer structure delivers this in a single package, with the high-g channel covering peak heel-strike deceleration (typically 5-10 g in elite sprinters but transient to 30-50 g on hard surfaces) and the low-g channel capturing the steady-state foot orientation. The ML core enables on-device gait-phase segmentation without streaming raw data over BLE.
Empfohlen
Industrial Vibration Monitoring
For predictive-maintenance vibration sensors on motors and bearings, the LSM6DSV80XTR's ±4000 dps gyroscope range and 80 g accelerometer capture high-frequency mechanical signatures while the on-device ML core runs anomaly classifiers at the edge. Operating over -40 °C to +85 °C industrial temperatures and consuming only 2.9 µA in low-power mode, the IMU enables battery-powered wireless sensor nodes that report only classified events. ST's STEVAL-MKI247A adapter board provides a quick prototyping reference for industrial deployments.
Empfohlen
Personal Trackers and Beacons
Bluetooth trackers such as luggage tags, key finders, and pet collars rely on always-on motion classification to preserve battery life. The LSM6DSV80XTR's 2.9 µA low-power current combined with its embedded ML core lets a tracker distinguish a 'picked up' event from ambient vibration without waking the host BLE SoC, extending coin-cell runtime by months. The wide 1.71 V to 3.6 V supply range accommodates the CR2032 discharge curve directly without boost circuitry.
Empfohlen
Zusammenfassung der empfohlenen Produkte
Technische Referenzdaten für LSM6DSV80XTR – Vergleich, Designhinweise und Compliance-Informationen.
Auswahlhilfe
Vergleich mit Alternativen
| Parameter | Dieses Produkt | LSM6DSV80X | LSM6DSO32X |
|---|---|---|---|
| Brand | STMicroelectronics | STMicroelectronics | STMicroelectronics |
| Package | LGA-14 (2.5x3 mm) | LGA-14 (2.5x3 mm) - same | LGA-14 (2.5x3 mm) - same |
| Accelerometer High-g Full Scale | ±80 g | ±80 g - same | ±32 g (-60%) |
| Accelerometer Low-g Full Scale | ±16 g | ±16 g - same | ±16 g - same |
| Supply Voltage | 1.71 V to 3.6 V | 1.71 V to 3.6 V - same | 1.71 V to 3.6 V - same |
| Sensor Fusion Engine | Yes (SFLP) | Yes (SFLP) | Yes (SFLP) |
| Operating Temperature | -40 °C to +85 °C | -40 °C to +85 °C | -40 °C to +85 °C |
Wichtigste Unterscheidungsmerkmale
- Dual 16 g / 80 g accelerometer in single package (vs. LSM6DSO32X)
- Embedded sensor-fusion low-power engine (vs. Generic external sensor-hub processor)
- I3C interface support (vs. I2C-only IMU predecessors)
Designhinweise
Place a 100 nF X7R ceramic decoupling cap directly on the LGA pads as close to pin 1 (VDD) and pin 3 (VDDIO) as possible, plus a 10 µF bulk capacitor on VDDIO. The 2.5x3 mm LGA has an integrated ground paddle on the underside - this MUST be soldered to a contiguous ground pour with multiple thermal vias to the inner ground plane, both for electrical grounding and to spread the IMU's self-heating uniformly across the PCB.
Do not assume the part operates at the legacy I3C default bus voltage if your MCU is I2C-only: confirm VDDIO matches your host rail (typically 1.8 V or 3.3 V). Verify the host firmware supports I3C dynamic address assignment before relying on I3C mode - falling back to I2C reduces throughput but preserves compatibility. Always assert the CS pin high in SPI mode to avoid bus contention.
Keep the IMU isolated from mechanical stress: mount near the geometric center of the PCB on a stiffened section, and avoid placing tall components within 5 mm of the LGA. Mechanical stress from board flexure is the dominant source of offset drift in MEMS IMUs; symmetric mounting and stiffeners cut stress-induced bias shifts by an order of magnitude compared with corner placement.
The MEMS accelerometer zero-g offset drifts with temperature at a rate of approximately ±0.1 mg/°C typical - calibrate the zero-g offset at the application's operating temperature band (e.g., at 25 °C and 40 °C for body-worn devices) for high-accuracy tilt or orientation outputs. The integrated temperature sensor can drive the fill loop in real time at the cost of a small increase in active current.
Compliance-Informationen
RoHS compliant per JLCPCB listing. Not AEC-Q100 qualified - commercial-grade IMU for wearables and industrial use. For automotive applications requiring AEC-Q100, consult ST's automotive-grade IMU portfolio.