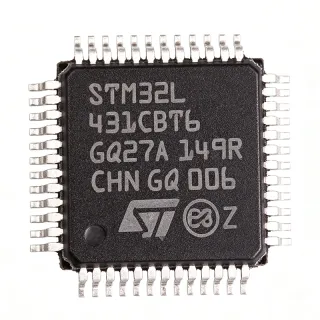
MPC563CZP66 - 32-bit PowerPC MCU 512KB Flash 66MHz 388-PBGA | NXP
Référence : MPC563CZP66 ⚠ Dernier achat| Qté | Prix unitaire | Total |
|---|---|---|
| 1 | $28.5 | $28,50 |
| 10 | $25.4 | $254,00 |
| 100 | $22.1 | $2 210,00 |
| 500 | $19.85 | $9 925,00 |
| 1 000 | $17.6 | $17 600,00 |
MPC563CZP66 Présentation
A PowerPC microcontroller is a RISC-based embedded processor that combines a high-performance CPU with on-chip peripherals, Flash, RAM, and communication interfaces in a single device. PowerPC cores, derived from IBM's POWER architecture, offer deterministic interrupt latency, strong real-time behavior, and broad automotive-grade qualification. Within the system hierarchy, an MCU sits between a microprocessor (MPU) and a microcontroller with application-specific peripherals, serving as the central processing element in embedded control systems.
Key specifications include 512 KB of on-chip Flash organized as 512K x 8 bits, 32 KB SRAM, a 66 MHz maximum CPU clock, 56 I/O pins, and a 388-ball Plastic BGA (PBGA) package. The integrated peripherals typically include a CAN 2.0B controller, queued SPI, queued UART, MI bus interface, and a time processor unit supporting DC motor and brushless DC motor PWM generation. The MPC563 belongs to the CMF (Common Memory Family) architecture with separate instruction and data paths.
The MPC563 architecture uses a Harvard-style memory organization with separate CMF_A and CMF_B Flash arrays, allowing concurrent instruction fetch and data operations. The CPU supports hardware multiply and divide, a barrel shifter, and dedicated registers for context switching, enabling responsive real-time control of mechanical systems.
Typical applications include automotive engine control units (ECUs), electronic power steering, transmission control modules, body controllers, industrial servo drives, and CAN-connected industrial automation equipment. The combination of automotive qualification, CAN bus support, and integrated motor-control peripherals makes it particularly well-suited for vehicle powertrain and chassis systems.
A key design consideration when using the MPC563CZP66 is that it is a mature, legacy part approaching end-of-life status; long-term availability should be verified before committing to new designs. Developers should also consider the 27 x 27 mm BGA package footprint, which requires multi-layer PCB design with controlled-impedance routing and BGA assembly capability.
This page synthesizes distributor pricing, drop-in same-family alternatives, and practical design notes not found in the manufacturer datasheet alone.
Alternatives de remplacement direct pour MPC563CZP66 — même boîtier, compatible broche à broche. Les références à boîtier différent nécessitant une retouche du PCB sont exclues.
Outil de comparaison rapide — sélectionnez des références alternatives pour une comparaison côte à côte :
MPC562CZP66
✅ Remplacement direct📋 Alternative de référence (hors catalogue)
MPC563MZP66
✅ Remplacement direct📋 Alternative de référence (hors catalogue)
MPC564AZP66
✅ Remplacement direct📋 Alternative de référence (hors catalogue)
MPC565AZP66
✅ Remplacement direct📋 Alternative de référence (hors catalogue)
MPC555AZP66
✅ Remplacement direct📋 Alternative de référence (hors catalogue)
MPC563CZP66 Valeurs maximales et caractéristiques électriques
| Manufacturer | NXP Semiconductors |
| Series | MPC5xx |
| Core Processor | PowerPC MPC5xx |
| Core Size | 32-Bit |
| Core Architecture | RISC / Harvard-style CMF |
| Maximum CPU Clock | 66 MHz |
| Program Memory Size | 512 KB (512K x 8) |
| Program Memory Type | FLASH |
| RAM Size | 32 KB (32K x 8) |
| Number of I/O | 56 |
| Boîtier / Format | 388-PBGA (27 mm x 27 mm) |
| Type de montage | Surface Mount |
| Oscillator Type | External |
| Temperature Grade | Industrial |
| Connectivity | CAN 2.0B, MI Bus, QSM (queued SPI/UART) |
| Peripherals | PWM, Time Processor Unit, Watchdog |
Guide de configuration des broches du MPC563CZP66 388-pbga (27 mm x 27 mm)
Configuration des broches du MPC563CZP66 (boîtier 388-pbga (27 mm x 27 mm)). Ce circuit intégré numérique comprend des GPIO, des interfaces de communication (UART, SPI, I2C) et des broches d'alimentation. Consultez la fiche technique du fabricant pour les fonctions alternatives des broches et les options de configuration. Indispensable pour la conception de systèmes embarqués et la conception de circuits imprimés.

Aucune donnée de brochage détaillée disponible pour MPC563CZP66.
Consultez la fiche technique pour la configuration complète des broches.
Applications typiques
MPC563CZP66 convient pour 6 applications: Automotive Engine Control Unit (ECU), Electronic Power Steering (EPS), Transmission Control Module (TCM), Industrial Servo Drive, CAN-Connected Industrial Automation, Body Control Module (BCM).
Automotive Engine Control Unit (ECU)
The MPC563CZP66 is well-suited for engine control unit applications, particularly in powertrain platforms with 4-cylinder gasoline or diesel engines requiring deterministic real-time performance. The 66 MHz PowerPC core provides sufficient throughput for crank position decoding, fuel injection pulse-width calculation, and idle speed control loops. The integrated Time Processor Unit (TPU) executes microcoded routines for crankshaft and camshaft sensing, replacing external hardware timers. The 512 KB Flash supports dual-bank operation for over-the-air calibration updates. According to the NXP MPC563 datasheet, 16 TPU channels can be assigned to individual fuel injectors and ignition coils, allowing 8-cylinder engine management on a single MCU. The CAN 2.0B interface provides bus connectivity to the rest of the vehicle network, and the 32 KB RAM is adequate for closed-loop control variables and OBD-II diagnostic stacks.
Recommandé
Electronic Power Steering (EPS)
The MPC563CZP66 fits electronic power steering controllers where precise torque-feedback sampling and motor-current regulation are required. The 66 MHz CPU executes the steering-assist algorithm and torque-overlay logic with deterministic interrupt latency from the integrated interrupt controller. The 56 I/O pins allow direct interface to torque sensors, resolver excitation, motor-driver PWM inputs, and the vehicle CAN bus. The TPU generates center-aligned PWM at 20 kHz or higher, sufficient for steering-motor current control. According to the NXP reference designs, the 32 KB RAM is sufficient for the Kalman-filter-based torque estimation and assist-curve lookup tables. The industrial temperature grade and 388-PBGA package provide the thermal margin required for under-hood mounting.
Recommandé
Transmission Control Module (TCM)
The MPC563CZP66 suits automatic transmission control modules where hydraulic-pressure scheduling, gear-shift timing, and torque-converter lockup are coordinated. The TPU's 16 channels map to multiple shift solenoids, pressure regulators, and torque-converter clutch control. The 512 KB Flash stores shift maps, adaptive learning parameters, and OBD-II diagnostics for the transmission subsystem. According to the NXP MPC563 datasheet, the CAN 2.0B interface supports the vehicle powertrain CAN bus at 500 kbps. The 66 MHz CPU handles real-time control of hydraulic pressure with closed-loop sampling rates up to 1 kHz. The 32 KB SRAM accommodates transmission-state variables, gear-ratio tables, and torque-intervention logic.
Recommandé
Industrial Servo Drive
The MPC563CZP66 is used in industrial servo drives where brushless DC or AC servo motors are controlled in CNC machines, robotics, and factory automation. The TPU microcoded routines support field-oriented control (FOC) of three-phase motors with sub-microsecond timing resolution. The 56 I/O pins interface to encoder feedback, Hall sensors, gate-driver PWM outputs, and CANopen or DeviceNet communication. The 66 MHz CPU runs the FOC loop at 8-16 kHz with comfortable headroom for trajectory planning and safety monitoring. According to NXP's MPC563 industrial reference design, the 32 KB RAM is sufficient for FOC state variables and trajectory buffer, while the 512 KB Flash stores motor-parameter autotuning data and application firmware.
Recommandé
CAN-Connected Industrial Automation
The MPC563CZP66 is appropriate for industrial programmable logic controllers (PLCs), remote I/O blocks, and CANopen slave devices. The CAN 2.0B interface with 16 mailboxes supports full CANopen or DeviceNet protocol stacks, while the UART and SPI interfaces connect to digital I/O expanders and analog front ends. The 56 GPIO lines handle digital input sampling, output driving, and fieldbus status LEDs. According to the NXP MPC563 datasheet, the MI Bus (Motorola Interconnect) interface allows low-cost peripheral expansion without using GPIOs. The 512 KB Flash stores the CANopen object dictionary and IEC 61131-3 application code, and the 32 KB RAM supports real-time I/O image updates.
Recommandé
Body Control Module (BCM)
The MPC563CZP66 is used in automotive body control modules where it manages lighting, door locks, wipers, and interior accessories via LIN and CAN networks. The 56 I/O lines drive relays and H-bridges for window lifts and seat adjusters. The TPU provides timed outputs for PWM-dimmed interior lighting, while the CAN interface connects to the vehicle body network. According to the NXP MPC563 datasheet, the queued serial module (QSM) supports SPI for direct connection to LED drivers and EEPROM. The 32 KB RAM supports network management and diagnostic buffers, and the 512 KB Flash stores application logic and LIN-descriptor files. The part's industrial temperature rating is adequate for cabin-mounted BCMs.
Recommandé
Récapitulatif des produits recommandés
Données de référence d'ingénierie pour MPC563CZP66 — comparaison, recommandations de conception et informations de conformité.
Guide de sélection
Comparaison avec les alternatives
| Paramètre | Ce produit | MPC562CZP66 | MPC563MZP66 | MPC564AZP66 | MPC565AZP66 | MPC555AZP66 |
|---|---|---|---|---|---|---|
| Brand | NXP Semiconductors | NXP Semiconductors | NXP Semiconductors | NXP Semiconductors | NXP Semiconductors | NXP Semiconductors |
| Package | 388-PBGA (27x27) | 388-PBGA (27x27) - same | 388-PBGA (27x27) - same | 388-PBGA (27x27) - same | 388-PBGA (27x27) - same | 388-PBGA (27x27) - same |
| CPU Clock | 66 MHz | 66 MHz | 66 MHz | 66 MHz | 56 MHz (dual-issue) | 40 MHz (-39%) |
| Flash Memory | 512 KB | 256 KB (-50%) | 512 KB | 1024 KB (+100%) | 1024 KB (+100%) | 448 KB (-13%) |
| RAM Size | 32 KB | 32 KB | 32 KB | 32 KB | 36 KB | 26 KB |
| Number of I/O | 56 | 56 | 56 | 56 | 56 | 56 |
| Core Architecture | PowerPC MPC5xx | PowerPC MPC5xx | PowerPC MPC5xx | PowerPC MPC5xx | PowerPC MPC5xx (dual-issue) | PowerPC MPC5xx |
| Lifecycle Status | Last Time Buy | Obsolete | Last Time Buy | Obsolete | Obsolete | Obsolete |
Principaux différenciateurs
- Larger Flash than MPC562CZP66 at same package (vs MPC562CZP66)
- Higher CPU clock than MPC555AZP66 (vs MPC555AZP66)
- Better availability than obsolete siblings (vs MPC564AZP66 / MPC565AZP66)
Notes de conception
The 388-PBGA package at 27 mm x 27 mm requires a multi-layer PCB with at least 4 layers for signal escape, power distribution, and ground-plane integrity. Use microvia-in-pad or via-in-pad technology (IPC-7093 class 3) for the BGA fanout to maintain signal integrity at 66 MHz. Per JEDEC J-STD-020, the reflow profile should not exceed 245 C peak for the PBGA. Decoupling capacitors must be placed within 5 mm of the power balls with 100 nF X7R ceramic for high-frequency and 4.7 uF X5R for bulk decoupling.
The 388-PBGA package has a theta_JA of approximately 18-22 C/W depending on PCB thermal design, which must be considered for under-hood automotive applications with ambient temperatures up to 105 C. At 66 MHz full CPU activity, internal power dissipation is roughly 0.8 W, producing a junction-temperature rise of 14-18 C above ambient. For sealed modules without airflow, expose thermal balls to a continuous ground plane and consider copper-filled thermal vias under the package to spread heat. According to NXP thermal modeling guidelines, the industrial temperature grade is maintained when junction stays below 125 C.
Do not confuse the MPC563CZP66 with the MPC563MZP66 - both are 388-PBGA but with different ball-maps. Verify the mechanical outline before PCB fabrication. The Flash requires a 5 V programming voltage supplied through dedicated VPP pins during in-circuit programming; if these pins are not driven to the proper voltage, programming will fail silently. According to the NXP MPC563 errata document, the TPU microcode reload must be performed at every CPU reset, not only at power-on. Designers using the CAN 2.0B interface should enable the receive message buffer interrupts and configure the clock source per the MPC500 reference manual to avoid bus-off errors.
Informations de conformité
Compliance data was not provided in the verified web data and must be verified on the official NXP product page. The part was originally released by Freescale Semiconductor; compliance statements should be confirmed against the NXP product page under the legacy Freescale product family.