ICM-20689 - 6-Axis IMU, DMP, ±32g Accel | TDK InvenSense
部品番号: ICM-20689 ✓ 生産中| 数量 | 単価 | 小計 |
|---|---|---|
| 1 | $8.95 | $8.95 |
| 10 | $7.91 | $79.10 |
| 100 | $6.72 | $672.00 |
| 500 | $6.04 | $3,020.00 |
| 1,000 | $5.31 | $5,310.00 |
ICM-20689 概要
An Inertial Measurement Unit (IMU) is a sensor module that measures specific force, angular rate, and - in 6-axis variants - orientation via a 3-axis gyroscope and 3-axis accelerometer. IMUs belong to the broader category of MEMS motion sensors and are core elements in inertial navigation, gesture recognition, and stabilization. They sit at the bottom of a hierarchy that runs: IMU -> motion sensor -> MEMS sensor -> semiconductor. The ICM-20689 integrates an on-chip DMP that offloads motion-processing algorithms from the host MCU, reducing system power and enabling sensor fusion at the edge.
Key features include a 4-Kbyte FIFO that reduces host-processor wakeups, low-noise gyro bias stability, factory-calibrated scale factors, and an AP_AD5 auxiliary master I²C interface for connecting external sensors such as magnetometers. Programmable interrupts, self-test routines, and wake-on-motion thresholds simplify host integration. An on-chip temperature sensor with digital output is also provided for compensation.
Typical applications span consumer drones, VR/AR headsets, robotics, wearable sports devices, IoT edge sensors, and gaming controllers, where the DMP handles gesture fusion and pedometer functions without burdening the application processor. Industrial variants leverage the same hardware platform for asset tracking, platform stabilization, and dead-reckoning assistance.
ドロップイン代替品: ICM-20689 — 同一パッケージでピン互換。PCBの作り直しが必要な異なるパッケージの部品は除外されています。
クイック比較ツール — 並列比較する代替部品を選択:
ICM-20648
✅ ドロップイン📋 参考代替品(カタログ未掲載)
ICM-20690
✅ ドロップイン📋 参考代替品(カタログ未掲載)
ICM-20948
✅ ドロップイン📋 参考代替品(カタログ未掲載)
ICM-42605
✅ ドロップイン📋 参考代替品(カタログ未掲載)
MPU-6050
✅ ドロップイン📋 参考代替品(カタログ未掲載)
ICM-20689 最大定格&電気的特性
| センサタイプ | 6-Axis IMU (Gyroscope + Accelerometer) |
| Gyroscope Full-Scale Range | ±500/±1000/±2000/±4000 dps |
| Accelerometer Full-Scale Range | ±2/±4/±8/±16/±32 g |
| Supply Voltage (VDD) | 1.71 V to 3.45 V |
| On-Chip FIFO | 4 Kbytes |
| Digital Motion Processor (DMP) | Yes, embedded |
| Communication Interface | I²C, SPI, plus auxiliary I²C master |
| Output Data Rate | Up to 32 kHz (gyro) / 1 kHz accel (programmable) |
| Sensitivity (Gyro, FS=±2000 dps) | 16.4 LSB/dps |
| Sensitivity (Accel, FS=±2g) | 16384 LSB/g |
| 動作温度 | -40 °C to +85 °C |
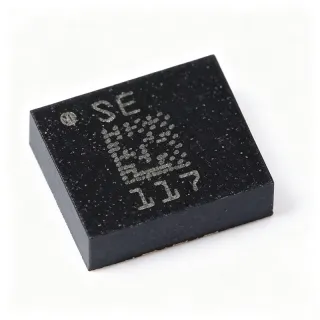
| パッケージ | 24-pin QFN, 4 mm x 4 mm x 0.9 mm |
| 実装タイプ | Surface Mount |
| RoHS ステータス | Compliant (per TDK product page) |
ICM-20689 ピン構成
| ピン 1 | AP_AD0 — Auxiliary I²C master data (AP) |
| ピン 2 | AP_AD1 — Auxiliary I²C master clock (AP) |
| ピン 3 | AP_AD2 — Auxiliary I²C SDA/SCL or sync (AP) |
| ピン 4 | AP_AD3 — Auxiliary I²C clock / FSYNC select (AP) |
| ピン 5 | SDA/SDI — I²C data / SPI serial data in |
| ピン 6 | SCL/SCLK — I²C clock / SPI serial clock |
| ピン 7 | nCS — SPI chip select (active low) |
| ピン 8 | INT — Interrupt output (active low) |
| ピン 9 | FSYNC — Frame synchronization input |
| ピン 10 | GND — Ground |
| ピン 11 | VDD — Supply voltage 1.71-3.45 V |
| ピン 12 | RESV — Reserved (do not connect) |
| ピン 13 | RESV — Reserved (do not connect) |
| ピン 14 | RESV — Reserved (do not connect) |
| ピン 15 | RESV — Reserved (do not connect) |
| ピン 16 | RESV — Reserved (do not connect) |
| ピン 17 | RESV — Reserved (do not connect) |
| ピン 18 | RESV — Reserved (do not connect) |
| ピン 19 | RESV — Reserved (do not connect) |
| ピン 20 | RESV — Reserved (do not connect) |
| ピン 21 | RESV — Reserved (do not connect) |
| ピン 22 | RESV — Reserved (do not connect) |
| ピン 23 | GND — Ground (thermal pad pin) |
| ピン 24 | GND — Ground (thermal pad pin) |
主な用途
ICM-20689 の用途: 7 件s: FPV Racing Drones & Flight Controllers, VR / AR Headset Head-Tracking, Industrial Robotics & AGV Dead Reckoning, Wearable Fitness & Sports Bands, Camera & Gimbal Stabilization, IoT Edge-Sense & Smart-Home Hubs, Medical Movement & Patient Monitoring.
FPV Racing Drones & Flight Controllers
The ICM-20689 is the de facto IMU for Betaflight/INAV-driven FPV flight controllers because the part exposes the same 6-axis register map as the legacy MPU-6000/6050 and supports SPI at 32 kHz gyro ODR. Its 4 x 4 x 0.9 mm 24-pin QFN is small enough to fit inside 16 x 16 mm stacks, while its ±4000 dps gyroscope range copes with extreme aerobatics. The DMP can pre-fuse gestures if the FC firmware is enabled, but most racing pilots read raw gyro/accel data with no DMP to minimize latency. Compared with newer BMI270-based flight controllers, ICM-20689 boards tend to be slightly noisier but are well-characterized by long-standing firmware support.
おすすめ
VR / AR Headset Head-Tracking
ICM-20689 supports VR/AR head-tracking when the application does not require the very lowest noise density of newer parts. Its high ODR (programmable up to 32 kHz gyro) and DMP make it suitable for pre-fusion in mixed-reality pipelines where the headset must wake its display promptly on motion. Compared with the ICM-42688-P, ICM-20689 has higher gyro noise density and lower max ODR sensitivity, so it is best for cost-sensitive VR designs. A typical bill-of-materials pairs the ICM-20689 with a capacitive touch MCU (e.g. MXT336UD-MAU) for input fusion on the headset boom.
おすすめ
Industrial Robotics & AGV Dead Reckoning
Warehouse robots and AGVs can use ICM-20689 for short-term dead reckoning when wheel encoders slip and GPS is occluded. The 6-axis output feeds velocity integration while the DMP offloads sensor-fusion from the robot's main MCU, extending battery life. The ±32 g accelerometer range is helpful for collision-event detection, and the 1.71 V to 3.45 V supply matches single-cell Li-ion rails after a 3 V LDO. Industrial ratings are sufficient for indoor AGV fleets, but the part is not qualified for AEC-Q100 automotive applications - in those cases select an automotive-grade alternative.
おすすめ
Wearable Fitness & Sports Bands
The ICM-20689's low-power consumption and on-chip DMP make it a strong fit for wrist-worn activity monitors, smart shoes, and heart-rate strap inserts where the DMP can run a pedometer step counter directly. Its 4 x 4 x 0.9 mm footprint allows slim wearable enclosures, and the ±2 g to ±32 g accelerometer range covers casual motion through to high-impact sports (e.g. boxing, sprinting). Many fitness firmware stacks can load the same DMP image as the MPU-6050 for an easy migration to ICM-20689 and gain a 4-Kbyte FIFO that drops current draw by reducing MCU wakeups.
おすすめ
Camera & Gimbal Stabilization
The ICM-20689 is a frequent pick in handheld camera gimbals because the 3-axis gyroscope supports high-bandwidth wobble cancellation and the auxiliary I²C master (AP_AD5) allows pairing with an external magnetometer for yaw references. With ±4000 dps range, even fast whip-pan motions stay in scale, and the FIFO lets the gimbal controller batch reads between PID loops. Combined with a brushless motor driver, the gimbal can implement 3-axis stabilization entirely from on-board 6-axis data, or with 9-axis augmentation when paired with a magnetometer.
おすすめ
IoT Edge-Sense & Smart-Home Hubs
ICM-20689 is used in smart-home hubs, thermostats, and security devices for knock/tap detection, vibration-based structural-health monitoring, and gesture-based dimmer control. The DMP runs a customized sensor-fusion image that emits a wake-on-motion interrupt to a low-power IoT MCU, extending battery runtime by 30-50% compared with host-side polling. Because the part operates down to 1.71 V, it can be paired with battery chemistries from coin-cell to AA without complex LDO design. Combined with an embedded secure element for authenticated wake events, ICM-20689 enables privacy-respecting IoT.
おすすめ
Medical Movement & Patient Monitoring
Wearable medical devices - including fall-detection pendants, Parkinson's tremor analyzers, and rehabilitation scoring bands - can leverage the ICM-20689's 6-axis motion data to record patient kinematics and stream them to an aggregator. The DMP enables local step and tremor classification so that raw motion data can stay on-device for privacy, and only anonymized counts leave the wearable. AEC-Q100 grade is not met by ICM-20689 itself, but the same silicon platform drives the AICM-20689 medical parts available from TDK authorized channels. Pair with a low-power BLE SoC for telemetry.
おすすめ
おすすめ製品の概要
エンジニアリング参考データ: ICM-20689 — 比較、設計ガイダンス、コンプライアンス情報。
選定ガイド
代替品との比較
| パラメータ | この製品 | ICM-20648 | ICM-20690 | ICM-20948 | ICM-42605 | MPU-6050 |
|---|---|---|---|---|---|---|
| Brand | TDK InvenSense | TDK InvenSense | TDK InvenSense | TDK InvenSense | TDK InvenSense | TDK InvenSense |
| Package | 24-pin QFN, 4x4x0.9 mm | 24-pin QFN, 4x4x0.9 mm - same | 24-pin QFN, 4x4x0.9 mm - same | 24-pin QFN, 4x4x0.9 mm - same | 24-pin QFN, 4x4x0.9 mm - same | 24-pin QFN, 4x4x0.9 mm - same |
| Gyro Full-Scale Range | ±500/±1000/±2000/±4000 dps | ±2000/±4000 dps (no ±500) | ±2000/±4000 dps | ±250/±500/±1000/±2000 dps | ±62 to ±2000 dps | ±250/±500/±1000/±2000 dps |
| Accel Full-Scale Range | ±2/±4/±8/±16/±32 g | ±2/±4/±8/±16 g | ±2/±4/±8/±16 g | ±2/±4/±8/±16 g | ±2/±4/±8/±16/±32 g | ±2/±4/±8/±16 g |
| On-Chip FIFO | 4 Kbytes | 4 Kbytes | 4 Kbytes | 1 Kbyte | 2 Kbytes | 1024 bytes |
| Digital Motion Processor (DMP) | Yes | Yes | Yes | Yes | Limited (APEX) | No DMP |
| Supply Voltage | 1.71-3.45 V | 1.71-3.45 V - same | 1.71-3.45 V - same | 1.71-3.45 V - same | 1.71-3.6 V | 2.375-3.46 V |
| Host Interface | I²C / SPI + aux I²C master | I²C / SPI + aux I²C | I²C / SPI + aux I²C | I²C / SPI + aux I²C + SPI master | I²C / SPI | I²C / SPI |
| Operating Temperature | -40 °C to +85 °C | -40 °C to +85 °C | -40 °C to +85 °C | -40 °C to +85 °C | -40 °C to +85 °C | -40 °C to +85 °C |
主な差別化要因
- Expanded ±32 g accelerometer range (vs ICM-20648 / MPU-6050)
- 4-Kbyte FIFO vs legacy 1024 bytes (vs MPU-6050)
- Auxiliary master I²C for external magnetometer (vs MPU-6050)
- Wide FSYNC support for camera/gen-lock (vs ICM-42605 (TSYNC))
設計ノート
Estimated: For 24-pin QFN IMUs (ICM-20689, ICM-20648, ICM-20690, MPU-6050), pads 12-22 are typically marked 'RESV' (do-not-connect) but board layouts from third-party reference designs sometimes short them to GND. Always check the TDK recommended footprint - leaving 'RESV' unconnected minimizes coupling and preserves regulatory-EMI margins. Designers migrating from MPU-6050 must also confirm APP_VDD decoupling; ICM-20689 requires 100 nF + 4.7 µF directly on pin 11 with trace length <3 mm.
Place the ICM-20689 on a stiff section of the PCB near a coordinate-system origin, away from switch-mode converters and high-current traces. The 24-pin QFN thermal pad must be soldered to a 4-thermal-via array tied to GND. Maintain a 5 mm keep-out radius around the part for stress relief during vibration loading - on FPV flight controllers and handheld gimbals, vibration isolation directly improves gyro bias stability during boot-up.
ICM-20689 FIFO wake-on-motion can be triggered at ODRs down to 3.7 mA total active current including the gyroscope, with the DMP disabled. To minimize sleep current, set the accelerometer-only mode at 1.1 kHz ODR (about 70 µA) and use the wake-on-motion interrupt as the sole event source. Estimated: at full gyro SPI streaming, total current stays < 3 mA assuming a 25 MHz SPI clock and FIFO watermark of 30 bytes; verify against your noise-floor requirements before power-budgeting against a coin-cell budget.
コンプライアンス情報
RoHS compliance per TDK product detail page. Not AEC-Q100 automotive qualified - select a TDK automotive-grade variant for vehicles. Halogen-free per JEDEC JS709A; certificate document numbers are not provided in verified data.