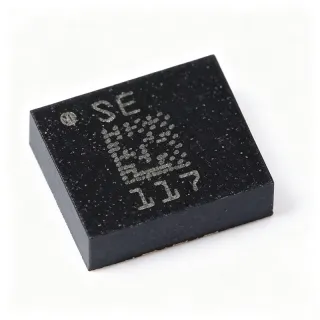
MMA1260KEG - ±1.5g Low-G Micromachined Accelerometer | NXP
Teilenummer: MMA1260KEG ✗ Abgekündigt| Menge | Stückpreis | Gesamt |
|---|---|---|
| 1 | $8.5 | $8,50 |
| 10 | $7.65 | $76,50 |
| 100 | $6.8 | $680,00 |
| 500 | $6.05 | $3.025,00 |
| 1.000 | $5.4 | $5.400,00 |
| 3.000 | $4.85 | $14.550,00 |
MMA1260KEG Übersicht
An accelerometer is a micro-electromechanical sensor (MEMS) that measures proper acceleration along one or more axes and converts the physical displacement of a proof mass into an analog or digital output proportional to g-force. Within the broader hierarchy, the MMA1260KEG belongs to the single-axis analog accelerometer class, which sits under MEMS motion sensors, then inertial measurement units, and finally the broader category of position and motion sensors. Analog-output accelerometers remain preferred where designers want direct interface to an ADC without an embedded digital engine.
Key features include a ±1.5 g measurement range, self-test capability that verifies mechanical and electrical integrity, factory-set zero-g offset and full-scale span, integrated temperature compensation, and a 2-pole low-pass filter with factory-set cutoff. The device operates from a single 5.0 V supply, draws typically 5.0 mA of supply current, and produces a ratiometric analog output centered at nominally 2.5 V at zero g. The on-chip signal conditioning eliminates the need for external compensation components.
The MMA1260KEG uses a surface-micromachined polysilicon sense element with interdigitated capacitor fingers suspended over fixed electrodes. Acceleration deflects the proof mass, changing the differential capacitance, which is read out by an on-chip sigma-delta architecture followed by a duty-cycle modulator output stage. This topology yields stable sensitivity versus temperature and voltage without external trim parts.
Typical applications include automotive airbag deployment sensing, electronic suspension control, tilt and inclination measurement, vibration monitoring in industrial equipment, and appliance anti-vibration control. Designers also use it in industrial machine health monitoring and gaming input devices where low-G motion detection is required.
When designing with this part, observe the recommended decoupling scheme of a 0.1 µF ceramic capacitor close to the supply pin and route analog output away from switching nodes. The self-test pin can be tied to a logic-level GPIO for in-system functional verification without applying external motion.
Drop-in-Alternativen für MMA1260KEG – gleiches Gehäuse, Pin-kompatibel. Bauteile mit anderem Gehäuse, die eine PCB-Überarbeitung erfordern, sind ausgeschlossen.
Varianten dieser Serie
Modelle derselben Serie, die drop-in-kompatibel sind mit MMA1260KEG (gleiche Bauform und Footprint) – abweichend in Measurement Range, Output Type, Sensor Type, Technology, Temperature Compensation.
Schnellvergleichstool – Wählen Sie Alternativbauteile für den Direktvergleich:
MMA1270KEG
✅ Drop-In✓ Auf Lager
$9.95 / Stück
Datenblatt ansehen →MMA1250KEG
✅ Drop-In📋 Referenzalternative (nicht im Katalog)
MMA1260KEGR2
✅ Drop-In📋 Referenzalternative (nicht im Katalog)
MMA1260KEG-574
✅ Drop-In📋 Referenzalternative (nicht im Katalog)
PMMA1260KEG
✅ Drop-In📋 Referenzalternative (nicht im Katalog)
MMA1260KEG Grenzwerte & elektrische Eigenschaften
| Sensortyp | Accelerometer, single-axis analog |
| Messbereich | ±1.5 g |
| Technology | Micromachined silicon capacitive MEMS |
| Versorgungsspannung | 5.0 V (typ) |
| Versorgungsstrom | 5.0 mA (typ) |
| Ausgangstyp | Analog, ratiometric |
| Zero-g Output Voltage | 2.5 V nominal at Vdd = 5.0 V |
| Filter | 2-pole low-pass, factory-set cutoff |
| Self-Test | Yes (logic-level activation) |
| Temperature Compensation | On-chip factory-calibrated |
| Betriebstemperaturbereich | -40 °C to +85 °C |
| Gehäuse | 16-pin SOIC (SOP-16 / K suffix) |
| Montageart | Surface Mount |
| RoHS-Status | Compliant |
MMA1260KEG Pin-Konfiguration
| Pin 1 | VDD — Positive supply voltage (5.0 V nominal) |
| Pin 2 | VOUT — Analog ratiometric acceleration output, 2.5 V at zero g |
| Pin 3 | GND — Ground reference |
| Pin 4 | ST — Self-test logic input, drive high to actuate electrostatic force |
| Pin 5 | NC — Not connected (per datasheet) |
| Pin 6 | NC — Not connected (per datasheet) |
| Pin 7 | NC — Not connected (per datasheet) |
| Pin 8 | NC — Not connected (per datasheet) |
| Pin 9 | NC — Not connected (per datasheet) |
| Pin 10 | NC — Not connected (per datasheet) |
| Pin 11 | NC — Not connected (per datasheet) |
| Pin 12 | NC — Not connected (per datasheet) |
| Pin 13 | NC — Not connected (per datasheet) |
| Pin 14 | NC — Not connected (per datasheet) |
| Pin 15 | NC — Not connected (per datasheet) |
| Pin 16 | NC — Not connected (per datasheet) |
Typische Anwendungen
MMA1260KEG ist geeignet für 6 Anwendungs: Tilt and Inclination Sensing, Industrial Vibration Monitoring, Appliance Anti-Vibration Control, Gaming and Motion Input Devices, Electronic Stability Control Front-End (Legacy Designs), Health and Fitness Wearables.
Tilt and Inclination Sensing
The MMA1260KEG's ±1.5 g range maps the full ±1 g gravitational tilt vector with comfortable headroom, while its on-chip temperature compensation keeps the zero-g output stable across outdoor thermal swings. The 2.5 V zero-g bias and ratiometric analog output simplify direct connection to a 5 V MCU ADC, eliminating the need for an extra reference. In solar trackers, agricultural equipment, and industrial platform leveling, this part replaces older mercury switches with a solid-state tilt element and integrates low-pass filtering to reject mechanical vibration.
Empfohlen
Industrial Vibration Monitoring
The MMA1260KEG's factory-set 2-pole low-pass filter limits high-frequency noise before it reaches the ADC, an advantage when monitoring motor bearing vibration or pump cavitation signatures in the sub-1 g envelope. The self-test pin lets a microcontroller confirm transducer integrity at every power-up, supporting predictive-maintenance regimes where sensor health is logged alongside vibration spectra. Combined with the 16-pin SOIC's robust surface-mount package, the part tolerates industrial thermal and mechanical environments while keeping the BOM simple.
Empfohlen
Appliance Anti-Vibration Control
Washing machines, dishwashers, and refrigerator compressors benefit from the MMA1260KEG's low-G analog output that feeds a microcontroller running a load-balancing or anti-vibration algorithm. The 5 mA quiescent current keeps standby power low, while the on-chip temperature compensation maintains accurate calibration through hot compressor cycles. The single-axis sensitivity simplifies PCB layout and the SOIC-16 footprint makes the part easy to place near a vibration source on a board edge for best signal fidelity.
Empfohlen
Gaming and Motion Input Devices
The MMA1260KEG's ±1.5 g range suits gesture controllers and motion-input peripherals where users perform slow, deliberate tilts rather than high-G swings. The ratiometric output means designers can power the sensor from the same 5 V rail as the gaming MCU's analog supply, sharing a stable reference and eliminating ground-loop errors. On-chip low-pass filtering removes the high-frequency buzz from nearby switch-mode regulators, which would otherwise couple into the analog output as spurious tilt readings.
Empfohlen
Electronic Stability Control Front-End (Legacy Designs)
Legacy automotive electronic-stability designs that pre-date modern high-G IMUs used MMA-series single-axis accelerometers like the MMA1260KEG as front-end tilt sensors. Although the part is now NRND, existing ECUs continue to source it because its calibration, pinout, and footprint are already validated in deployed vehicle platforms. Modern automotive designs should target AEC-Q100-qualified successors, but field-replacement and end-of-life service channels keep the MMA1260KEG in the supply chain.
Empfohlen
Health and Fitness Wearables
Wearable fitness bands measuring posture, walking gait, or activity classification benefit from the MMA1260KEG's low-G dynamic range, which captures everyday human motion without saturation. The integrated low-pass filter removes high-frequency muscle-noise artifacts, while the SOIC-16 footprint supports hybrid rigid-flex assemblies where the accelerometer sits on a small daughter board. Battery-powered wearables can duty-cycle the part because the analog output settles quickly at power-up, an advantage over digital-output sensors with longer boot delays.
Empfohlen
Zusammenfassung der empfohlenen Produkte
Technische Referenzdaten für MMA1260KEG – Vergleich, Designhinweise und Compliance-Informationen.
Auswahlhilfe
Vergleich mit Alternativen
| Parameter | Dieses Produkt | MMA1270KEG | MMA1250KEG | MMA1260KEGR2 | MMA1260KEG-574 | PMMA1260KEG |
|---|---|---|---|---|---|---|
| Brand | NXP Semiconductors | NXP Semiconductors | NXP Semiconductors | NXP Semiconductors | NXP Semiconductors | NXP Semiconductors |
| Package | 16-pin SOIC (K suffix) | 16-pin SOIC (K suffix) - same | 16-pin SOIC (K suffix) - same | 16-pin SOIC (K suffix) - same | 16-pin SOIC (K suffix) - same | 16-pin SOIC (K suffix) - same |
| Measurement Range | ±1.5 g | ±2.5 g | ±5 g | ±1.5 g | ±1.5 g | ±1.5 g |
| Supply Voltage | 5.0 V typ | 5.0 V typ | 5.0 V typ | 5.0 V typ | 5.0 V typ | 5.0 V typ |
| Supply Current | 5.0 mA typ | 5.0 mA typ | 5.0 mA typ | 5.0 mA typ | 5.0 mA typ | 5.0 mA typ |
| Output Type | Analog, ratiometric | Analog, ratiometric | Analog, ratiometric | Analog, ratiometric | Analog, ratiometric | Analog, ratiometric |
| Self-Test | Yes | Yes | Yes | Yes | Yes | Yes |
| Lifecycle Status | NRND | NRND | NRND | NRND | Active (Rochester traceable stock) | Active |
Wichtigste Unterscheidungsmerkmale
- Factory-calibrated for ±1.5 g low-G tilt and inclination tasks (vs. MMA1270KEG)
- On-chip signal conditioning eliminates external compensation parts (vs. MMA1250KEG)
- Ratiometric analog output simplifies ADC interface (vs. MMA2200 (legacy high-G part))
Designhinweise
Power the MMA1260KEG from a clean, low-noise 5.0 V regulator. Place a 0.1 µF ceramic decoupling capacitor within 3 mm of the VDD pin and a 1 µF bulk capacitor on the same rail. Because the analog output is ratiometric to VDD, sharing the same regulator reference with the MCU's ADC removes ratiometric errors caused by supply drift.
Route the VOUT trace away from switching-node traces such as DC-DC converter SW nodes or motor phase lines. Use a ground guard ring around the SOIC footprint to keep digital noise from coupling into the analog output. Keep the SOIC-16 mounted rigidly to the PCB so vibration energy transfers cleanly to the MEMS proof mass without parasitic board flex modes.
Avoid driving the self-test pin until VDD has fully stabilized, or the simulated deflection delta will be incorrect and may trigger false self-test failures. Do not load VOUT with capacitive loads greater than the datasheet-rated drive capability, and always buffer the output with an op-amp if driving long cables or low-impedance ADC inputs.
The on-chip 2-pole low-pass filter has a factory-set cutoff; for higher-frequency vibration analysis where you need raw bandwidth, sample VOUT with an ADC clocked well above the filter cutoff and apply digital filtering in firmware. For tilt-only applications, configure the MCU ADC to oversample and average to push effective resolution below the analog noise floor.
Compliance-Informationen
RoHS-compliant per NXP product page. Not AEC-Q100 qualified; not recommended for new automotive safety designs. Reach and conflict-minerals declarations follow NXP standard corporate compliance.