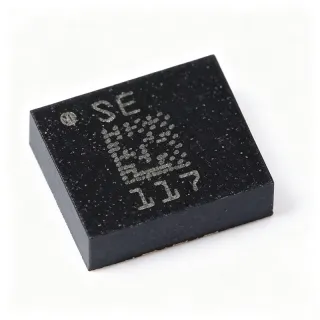
LSM6DSO32XTR - 32g 6-Axis IMU with ML Core | ST
料号: LSM6DSO32XTR ✓ 量产中| 数量 | 单价 | 小计 |
|---|---|---|
| 1 | $4.9 | $4.90 |
| 10 | $4.45 | $44.50 |
| 100 | $3.95 | $395.00 |
| 500 | $3.55 | $1,775.00 |
| 1,000 | $3.2 | $3,200.00 |
LSM6DSO32XTR 概述
An inertial measurement unit is a motion sensor that fuses accelerometer and gyroscope outputs to track orientation, acceleration, and rotation. Within the sensor hierarchy, the IMU sits above discrete accelerometers and gyroscopes, and forms the core motion-sensing element of smartphones, wearables, drones, industrial condition-monitoring nodes, and robotics platforms. ST's iNEMO family is a leading MEMS IMU line, and the LSM6DSO32X extends it with the widest accelerometer range in the family.
Key differentiating features include the 32 g accelerometer full scale - four times the 16 g range of the standard LSM6DSO - which captures shock and vibration events without clipping. The device integrates an embedded finite state machine (FSM) and a Machine Learning Core (MLC) that run decision-tree logic on-chip, enabling always-on context detection such as fall detection, activity classification, and vibration fingerprinting with negligible host CPU load.
Technically, the sensor supports output data rates up to 6.66 kHz for the accelerometer and gyroscope, a smart FIFO for offloading data, hardware low-pass and high-pass filters, and an on-chip temperature sensor. Its always-on architecture with low-power and ultra-low-power modes makes battery-powered designs practical. The X variant additionally supports Sensor Fusion Low Power (SFLP), computing a game rotation vector in hardware.
Typical applications include drone and UAV flight controllers needing 32 g shock tolerance, industrial predictive-maintenance nodes detecting machine vibration signatures via the MLC, and high-impact sports wearables. ODR range and noise floor make it equally suited to premium motion tracking in AR/VR controllers.
Designers should pay attention to PCB placement: mount the part away from board flex zones and vibrating masses, and follow ST's layout guidelines for the LGA pads and ground plane continuity to preserve gyro bias stability.
This page synthesizes distributor pricing context, pin-compatible family alternatives, and practical design guidance beyond the raw ST datasheet, delivering information gain over generic catalog listings.
直接替换替代料: LSM6DSO32XTR ——相同封装,引脚兼容。需要 PCB 改动的不同封装料号已排除。
本系列中的变体
可与以下型号直接替换的同系列型号: LSM6DSO32XTR (相同外形与封装尺寸) ——差异在于 Package, Embedded Features, Sensor Type, Gyroscope Full-Scale Range, Operating Temperature.
快速对比工具——选择替代料号进行并排对比:
LSM6DSOXTR
✅ 直接替换 ⚠️ 规格未核验✓ 有现货
$1.58 / 个
查看数据手册 →LSM6DSOTR
✅ 直接替换 ⚠️ 规格未核验✓ 有现货
$2.65 / 个
查看数据手册 →LSM6DSRTR
✅ 直接替换 ⚠️ 规格未核验✓ 有现货
$4.1 / 个
查看数据手册 →LSM6DSV16XTR
✅ 直接替换 ⚠️ 规格未核验✓ 有现货
$1.95 / 个
查看数据手册 →LSM6DS3TR-C
✅ 直接替换 ⚠️ 规格未核验✓ 有现货
$0.875 / 个
查看数据手册 →LSM6DSO32XTR 最大额定值与电气特性
| 传感器类型 | 6-axis IMU (3-axis accelerometer + 3-axis gyroscope) |
| Accelerometer Full Scale | +/-2 g to +/-32 g (user selectable) |
| Gyroscope Full Scale | +/-125 dps to +/-4000 dps |
| Output Data Rate | Up to 6.66 kHz (accelerometer and gyroscope) |
| High-Performance Mode Current | 0.55 mA (typical) |
| 电源电压 | 1.71 V to 3.6 V |
| 接口 | I2C / SPI (3-wire and 4-wire) |
| Embedded Features | Finite State Machine (FSM), Machine Learning Core (MLC), Sensor Fusion Low Power (SFLP) |
| Temperature Sensor | Yes, on-chip |
| FIFO | Yes, smart FIFO with configurable watermark |
| Interrupts | 2 programmable hardware interrupt pins (INT1, INT2) |
| 封装 | LGA-14, 2.5 x 3.0 x 0.83 mm |
| 工作温度 | -40 C to +85 C |
| 安装类型 | Surface Mount |
| RoHS 状态 | Compliant |
LSM6DSO32XTR 引脚配置
| 引脚 1 | SDO/SA0 — SPI 4-wire serial data output / I2C least significant bit of device address |
| 引脚 2 | INT2 — Programmable interrupt 2 output |
| 引脚 3 | INT1 — Programmable interrupt 1 output |
| 引脚 4 | VDDIO — I/O pad supply voltage |
| 引脚 5 | GND — Ground |
| 引脚 6 | GND — Ground |
| 引脚 7 | VDD — Power supply |
| 引脚 8 | NC — Not connected (per datasheet) |
| 引脚 9 | NC — Not connected (per datasheet) |
| 引脚 10 | NC — Not connected (per datasheet) |
| 引脚 11 | SDx/SDA — I2C serial data master/slave / SPI 3-wire serial data input |
| 引脚 12 | SCx/SCL — I2C serial clock master/slave / SPI 3-wire serial clock |
| 引脚 13 | NC — Not connected (per datasheet) |
| 引脚 14 | GND — Ground |
典型应用
LSM6DSO32XTR 适用于 6 应用s: Drone and UAV Flight Control, Industrial Predictive Maintenance, Sports and Impact Wearables, AR/VR Controller Motion Tracking, Asset Tracking and Logistics Tags, Robotics Joint Monitoring.
Drone and UAV Flight Control
The LSM6DSO32XTR fits drone flight controllers because its +/-32 g accelerometer absorbs hard landings and propeller-wash shocks that saturate 16 g sensors, while the +/-4000 dps gyroscope tracks aggressive acrobatic maneuvers. Its 6.66 kHz maximum ODR gives the flight-control loop fresh angular-rate data fast enough for high-bandwidth attitude stabilization. In the control loop the IMU feeds the complementary or Kalman filter; the embedded FSM can trigger an interrupt on anomalous G-load, offloading crash detection from the MCU. At roughly 0.55 mA in high-performance mode, the sensor leaves ample power budget for video transmitters on battery-powered airframes.
推荐
Industrial Predictive Maintenance
For condition monitoring of motors, pumps, and gearboxes, the LSM6DSO32XTR's 32 g range captures high-amplitude vibration events without clipping, and its Machine Learning Core classifies vibration signatures - bearing wear, imbalance, misalignment - directly on the sensor using decision trees trained in ST's Unico/Unicleo tools. This means only a fault flag crosses the I2C/SPI bus, cutting system power versus continuous streaming. The smart FIFO buffers bursts during radio wake-up, and the on-chip temperature sensor supports thermal-context analysis. Mounted on the monitored housing with the PCB kept rigid, the device provides repeatable RMS vibration data up to several kHz of bandwidth.
推荐
Sports and Impact Wearables
In wearables for skiing, skateboarding, or contact sports, impacts routinely exceed 16 g; the LSM6DSO32XTR's 32 g full scale measures them faithfully for load quantification, while the Machine Learning Core runs activity and fall detection locally, extending battery life by keeping the MCU asleep. The always-on architecture and low-power modes maintain motion context at microamp-level currents between events. FIFO watermarks batch data for burst transfer over BLE modules via I2C. Designers should strap-mount the sensor close to the limb and configure the HP filter to remove DC gravity so that impact peaks, not tilt, dominate the detection features.
推荐
AR/VR Controller Motion Tracking
The LSM6DSO32XTR suits AR/VR controllers that undergo rapid wrist rotations and collisions with the environment: the 4000 dps gyroscope range prevents saturation during fast swings, and the 32 g accelerometer survives controller drops. The Sensor Fusion Low Power block computes a game rotation vector in hardware, delivering drift-corrected orientation at constant low power without burdening the controller SoC. Data travels over SPI at multi-kHz ODR for minimal latency, which is essential to perceived responsiveness in hand tracking. Its compact 2.5 x 3 mm LGA-14 footprint fits inside slim controller housings near the grip center of rotation.
推荐
Asset Tracking and Logistics Tags
Battery-powered shipment tags use the LSM6DSO32XTR to log handling abuse: the 32 g range records drops and shocks that 16 g parts would clip, and the FSM/MLC can trigger a 'shock event' flag plus timestamp into the FIFO at very low duty cycle. Ultra-low-power modes keep quiescent draw minimal during months of transit, waking only on programmable interrupts. Data is uploaded when the tag reaches a gateway, over BLE or NFC links. The on-chip temperature sensor adds cold-chain context without a second component. This combination of wide dynamic range, embedded decision logic, and always-on efficiency is precisely why ST targets tracking nodes with the X family.
推荐
Robotics Joint Monitoring
Collaborative-robot and gimbal joints benefit from the LSM6DSO32XTR's wide dynamic range: collisions and gear-head impacts generate accelerations well beyond 16 g, and the 4000 dps gyro range covers fast joint reversals. Placing one IMU per limb segment and streaming via SPI at high ODR lets the safety controller detect anomalies within milliseconds, while the MLC pre-classifies vibration signatures of gearbox degradation. The sensor's low 0.55 mA high-performance current allows several joints to be instrumented within a compact actuator power budget. Follow ST's layout guidance for a solid ground plane to preserve gyro bias stability under motor EMI.
推荐
推荐产品汇总
工程参考数据: LSM6DSO32XTR ——对比、设计指导和合规信息。
选型指南
与替代料对比
| 参数 | 本产品 | LSM6DSOXTR | LSM6DSOTR | LSM6DSV16XTR | LSM6DS3TR-C |
|---|---|---|---|---|---|
| Package | LGA-14 (2.5 x 3.0 x 0.83 mm) | LGA-14 (2.5 x 3.0 mm) - same | LGA-14 (2.5 x 3.0 mm) - same | LGA-14 (2.5 x 3.0 mm) - same | LGA-14 (2.5 x 3.0 mm) - same |
| Brand | STMicroelectronics | STMicroelectronics | STMicroelectronics | STMicroelectronics | STMicroelectronics |
| Accelerometer Full Scale | +/-32 g max | +/-16 g max | +/-16 g max | +/-16 g max | +/-16 g max |
| Gyroscope Full Scale | +/-4000 dps max | +/-2000 dps max | +/-2000 dps max | +/-4000 dps max | +/-2000 dps max |
| Machine Learning Core / FSM | Yes (MLC + FSM + SFLP) | Yes (MLC + FSM) | No | Yes (MLC v2 + FSM + SFLP) | No |
| Max Output Data Rate | 6.66 kHz | 6.66 kHz | 6.66 kHz | 7.68 kHz | 1.66 kHz |
| High-Performance Current | ~0.55 mA | ~0.65 mA | ~0.65 mA | ~0.75 mA | ~0.65 mA |
关键差异点
- Widest accelerometer range in the LSM6DSO family (对比 LSM6DSOXTR)
- Extended gyroscope range to 4000 dps (对比 LSM6DSOTR)
- Hardware sensor fusion (SFLP) on top of MLC and FSM (对比 LSM6DSOXTR)
设计说明
Place the LSM6DSO32XTR on a rigid section of the PCB, at least 5 mm away from mounting holes and board-edge flex zones; board strain couples directly into MEMS gyro zero-rate offset. Provide a continuous ground plane beneath the LGA-14 pads and follow ST's recommended pad geometry in the datasheet mechanical section to ensure good solder wetting. Decouple VDD and VDDIO with 100 nF ceramic capacitors placed within 2 mm of the pins, plus a 10 uF bulk capacitor on the VDD rail.
Keep I2C/SPI traces short (under 50 mm) and route them away from switching-regulator inductors and motor drives, which inject gyro-band noise through ground bounce. For SPI above 5 MHz, add series 22-33 ohm resistors on SCLK/SDI near the host to control ringing. When using the sensor-hub or FSM features with INT pins, treat INT1/INT2 as short local signals; long interrupt wires over noisy harnesses are a common false-trigger source.
Do not connect NC pins (8, 9, 10, 13) to any net - leave them floating per the datasheet, as they are reserved. Verify that VDDIO is never powered while VDD is absent for extended periods, and respect the 1.71-3.6 V supply range. When migrating from LSM6DSOTR firmware, remember that 32 g full scale and 4000 dps use different register settings, and sensor-fusion (SFLP) enable sequences differ; re-validate ODR/filter settings in ST's tools before release.
合规信息
RoHS compliance stated per ST product information. REACH, halogen-free and conflict-minerals declarations should be confirmed via the ST quality portal material datasheet for LSM6DSO32XTR.