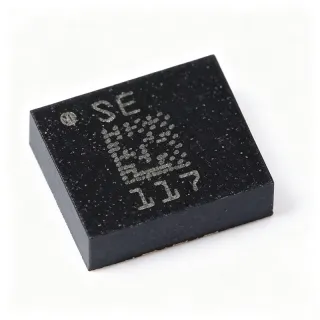
LSM9DS1TR - 9-Axis iNEMO IMU, ±16g Accel/±2000dps Gyro | STMicroelectronics
부품 번호: LSM9DS1TR ✓ 활성| 수량 | 단가 | 합계 |
|---|---|---|
| 1 | $12.19 | $12.19 |
| 10 | $11.45 | $114.50 |
| 100 | $9.85 | $985.00 |
| 500 | $8.95 | $4,475.00 |
| 1,000 | $8.1 | $8,100.00 |
LSM9DS1TR 개요
An Inertial Measurement Unit (IMU) is an electronic sensor module that measures and reports a body's specific force (acceleration), angular rate (rotation), and magnetic field heading. IMUs are core components in modern motion-aware electronics, sitting in the hierarchy of MEMS sensors -> motion sensors -> inertial sensors -> semiconductor devices. By integrating accelerometer, gyroscope, and magnetometer into a single SiP, the LSM9DS1TR eliminates the board space, alignment overhead, and fusion firmware complexity of three discrete sensors.
Key specifications include user-selectable full-scale ranges of ±2/±4/±8/±16 g for acceleration, ±245/±500/±2000 dps for angular rate, and ±4/±8/±12/±16 gauss for magnetic field, with output data rates up to 952 Hz (accel/gyro) and 80 Hz (magnetometer). The device includes an embedded FIFO buffer (up to 32 slots), two programmable interrupt generators for motion/ orientation/ magnetic-threshold wake-up events, an integrated temperature sensor, and a wide operating temperature range of -40 C to +85 C.
The LSM9DS1TR uses capacitive MEMS sensing elements for the accelerometer and gyroscope and a Hall-effect/magneto-resistive element for the magnetometer, with per-channel 16-bit ADCs providing high-resolution output. The integrated linear voltage regulator ensures stable analog supply even as VDD varies, while the FIFO and interrupt engine offload event detection from the host MCU, enabling aggressive power-down duty-cycling in battery-powered designs.
Typical applications include motion tracking in smartphones, wearables, and AR/VR headsets, gesture and activity recognition, gaming controllers, drone flight stabilization, robotics orientation, and industrial tilt/vibration monitoring. The wide range of programmable full-scale and ODR settings allows the same part to serve a phone pedometer and an industrial tilt sensor.
When designing with this part, place 100 nF decoupling close to VDD and follow ST's recommended power-up sequence in the datasheet. For best magnetometer accuracy, keep ferromagnetic material (e.g., connector shells, inductors, FPC shields) at least 5 mm away from the device.
This page synthesizes distributor pricing, drop-in alternatives, and practical design notes not found in the manufacturer datasheet, giving engineers a single decision-ready reference for the LSM9DS1TR.
드롭인 대체품: LSM9DS1TR — 동일 패키지, 핀 호환. PCB 재작업이 필요한 다른 패키지 부품은 제외됩니다.
이 시리즈의 변형
다음과 드롭인 호환되는 동일 시리즈 모델: LSM9DS1TR (동일 폼 팩터 및 풋프린트) — 차이점: Package, Current Consumption (Normal Mode), Interface, Gyroscope Full-Scale Range, Operating Temperature.
빠른 비교 도구 — 나란히 비교할 대체 부품을 선택하십시오:
LSM9DS1
✅ 드롭인📋 참조 대체품 (카탈로그에 없음)
LSM6DS3TR
✅ 드롭인✓ 재고 있음
$1.05 / 개
데이터시트 보기 →LSM6DSLTR
✅ 드롭인✓ 재고 있음
$1.85 / 개
데이터시트 보기 →LIS2MDLTR
✅ 드롭인✓ 재고 있음
$3.1263 / 개
데이터시트 보기 →LSM303AGRTR
✅ 드롭인✓ 재고 있음
$1.6 / 개
데이터시트 보기 →LSM9DS1TR 최대 정격 & 전기적 특성
| 센서 유형 | Accelerometer, Gyroscope, Magnetometer, Temperature (9-axis IMU) |
| 출력 유형 | I2C, SPI |
| Acceleration Full-Scale Range | ±2 g / ±4 g / ±8 g / ±16 g (selectable) |
| Gyroscope Full-Scale Range | ±245 dps / ±500 dps / ±2000 dps (selectable) |
| Magnetometer Full-Scale Range | ±4 / ±8 / ±12 / ±16 gauss (selectable) |
| Data Resolution | 16-bit per channel |
| Accelerometer ODR | Up to 952 Hz |
| Gyroscope ODR | Up to 952 Hz |
| Magnetometer ODR | Up to 80 Hz |
| Supply Voltage (VDD) | 1.9 V to 3.6 V |
| Supply Voltage (VDDIO) | 1.71 V to VDD + 0.1 V |
| 동작 온도 | -40 C to +85 C |
| 패키지 | LGA-24 (3.5 x 3.5 x 1.0 mm) |
| 실장 유형 | Surface Mount |
| Embedded FIFO | Yes, 32-slot |
| Interrupt Lines | 2 programmable (INT1, INT2) |
| RoHS 상태 | Compliant |
LSM9DS1TR 핀 구성
| 핀 1 | VDD — Power supply (1.9 V to 3.6 V) |
| 핀 2 | GND — Ground |
| 핀 3 | RES — Reserved - leave floating or connect to GND |
| 핀 4 | CS_AG — SPI chip-select for accel/gyro (active low) |
| 핀 5 | SPC — SPI serial port clock (accel/gyro & mag shared) |
| 핀 6 | SDI — SPI data input (MOSI) |
| 핀 7 | SDO_AG — SPI data output / I2C LSB address (accel/gyro) |
| 핀 8 | SDA — I2C serial data (shared) |
| 핀 9 | SCL — I2C serial clock |
| 핀 10 | INT1 — Interrupt 1 (programmable) |
| 핀 11 | INT2 — Interrupt 2 (programmable) |
| 핀 12 | DRDY — Data-ready output |
| 핀 13 | VDDIO — Digital I/O supply (1.71 V to VDD+0.1 V) |
| 핀 14 | GND — Ground |
| 핀 15 | RES — Reserved - leave floating |
| 핀 16 | CS_M — SPI chip-select for magnetometer (active low) |
| 핀 17 | SDO_M — SPI data output / I2C LSB address (magnetometer) |
| 핀 18 | C1 — Decoupling capacitor pin 1 |
| 핀 19 | C2 — Decoupling capacitor pin 2 |
| 핀 20 | GND — Ground |
| 핀 21 | RES — Reserved - leave floating |
| 핀 22 | RES — Reserved - leave floating |
| 핀 23 | GND — Ground |
| 핀 24 | GND — Ground (thermal pad) |
일반적인 애플리케이션
LSM9DS1TR 적합 용도: 6 애플리케이션s: Smartphone & Wearable Motion Tracking, AR/VR Headset Head Tracking, Drone Flight Stabilization, Industrial Tilt & Vibration Monitoring, Robotics Orientation & Navigation, Gaming & Gesture-Recognition Controllers.
Smartphone & Wearable Motion Tracking
The LSM9DS1TR's 9-axis output and 1.9-3.6 V supply match the Li-ion battery + PMIC rails of smartphones and smartwatches, where it drives step counting, screen-rotation, and gesture wake-up. The ±16 g accelerometer captures taps and pocket-removal events without saturating, while the 16-bit accel resolution supports fine fall-detection thresholds. The magnetometer enables compass heading for navigation apps, and the 32-slot FIFO + two INT lines offload event handling from the application processor, reducing system power. Place 100 nF decoupling within 2 mm of VDD for clean supply during accel/gyro burst reads.
추천
AR/VR Headset Head Tracking
The LSM9DS1TR delivers 9-axis data at up to 952 Hz (accel/gyro), which is the bandwidth needed for low-latency head-pose estimation in AR/VR headsets. The ±2000 dps gyroscope captures fast head rotations without saturation, and the magnetometer corrects yaw drift over time, reducing visible world-jitter. The wide 1.9-3.6 V supply lets the part ride directly on a headset's Li-ion or USB bus. Place the IMU on the front rigid frame, away from display-driver FPCs, and follow the datasheet's recommended power-up sequence in Section 2.2.1 to ensure all three sub-sensors initialize cleanly.
추천
Drone Flight Stabilization
The LSM9DS1TR's ±2000 dps gyroscope full-scale and 952 Hz ODR make it well suited to multirotor flight controllers running PID loops at 1-8 kHz. The accelerometer feeds the gravity reference for level-hold, while the magnetometer provides absolute heading for waypoint navigation and return-to-home. Operate the device from a 3.3 V BEC rail and isolate the IMU from frame vibration with a foam damper to avoid gyro bias drift. The two INT lines can be wired to the FC's edge-triggered GPIOs to deliver per-sample timestamps for sensor fusion. AEC-Q100 is not required here, so the industrial-grade LSM9DS1TR is sufficient.
추천
Industrial Tilt & Vibration Monitoring
The LSM9DS1TR's wide ±16 g accelerometer range captures vibration signatures on motors, pumps, and rotating equipment, while the gyroscope detects shaft tilt and oscillation. The 16-bit ADC resolution enables sub-degree tilt accuracy in static installations, and the temperature sensor supports ambient-compensated calibration. Use the FIFO and INT1 to wake a host MCU only when RMS vibration exceeds a threshold, achieving years of battery life on remote IIoT nodes. Place the IMU on the rigid equipment chassis, with 5 mm clearance to ferromagnetic fasteners to keep the magnetometer accurate.
추천
Robotics Orientation & Navigation
The LSM9DS1TR provides full 9-DoF data needed for robot attitude and heading reference (AHRS) algorithms, with the accelerometer measuring gravity, the gyroscope tracking rotation, and the magnetometer anchoring yaw against drift. The 32-slot FIFO buffers burst data during fast maneuvers, so the host MCU can service other tasks instead of polling at 1 kHz. The I2C/SPI interface allows easy attachment to STM32, ESP32, or Raspberry Pi Pico hosts. The LGA-24 3.5 x 3.5 mm package fits on a 30 x 30 mm robot brain board. Mount on the robot's central chassis to minimize rotational lever-arm error.
추천
Gaming & Gesture-Recognition Controllers
The LSM9DS1TR's combination of high-ODR accelerometer, gyroscope, and magnetometer enables precise motion-capture for game controllers, pointing devices, and air-mouse peripherals. The ±16 g / ±2000 dps ranges capture both subtle tilts and aggressive flicks, while the 16-bit resolution gives sub-degree accuracy for aim applications. The 1.9-3.6 V supply range works with both 2x AA alkaline (3 V) and single-cell Li-ion (3.7 V) battery packs, with the integrated LDO handling regulation. Connect INT1 to the host's wakeup GPIO so the controller can sleep between gestures and instantly resume on motion.
추천
추천 제품 요약
엔지니어링 참조 데이터: LSM9DS1TR — 비교, 설계 지침 및 규정 준수 정보.
선택 가이드
대체품과의 비교
| 파라미터 | 이 제품 | LSM9DS1 | LSM6DS3TR | LSM6DSLTR | LIS2MDLTR | LSM303AGRTR |
|---|---|---|---|---|---|---|
| Brand | STMicroelectronics | STMicroelectronics | STMicroelectronics | STMicroelectronics | STMicroelectronics | STMicroelectronics |
| Package | LGA-24 (3.5x3.5 mm) | LGA-24 (3.5x3.5 mm) | LGA-14 | LGA-14 | LGA-12 | LGA-12 |
| Axis Count | 9 (accel+gyro+mag) | 9 (accel+gyro+mag) | 6 (accel+gyro) | 6 (accel+gyro) | 3 (magnetometer) | 6 (accel+mag) |
| Accel Full-Scale | ±2/±4/±8/±16 g | ±2/±4/±8/±16 g | ±2/±4/±8/±16 g | ±2/±4/±8/±16 g | N/A (magnetometer) | ±2/±4/±8/±16 g |
| Gyro Full-Scale | ±245/±500/±2000 dps | ±245/±500/±2000 dps | ±125/±245/±500/±1000/±2000 dps | ±125/±245/±500/±1000/±2000 dps | N/A (magnetometer) | N/A (no gyro) |
| Magnetometer Full-Scale | ±4/±8/±12/±16 gauss | ±4/±8/±12/±16 gauss | N/A (no magnetometer) | N/A (no magnetometer) | ±50 gauss | ±50 gauss |
| Supply Voltage | 1.9 V to 3.6 V | 1.9 V to 3.6 V | 1.71 V to 3.6 V | 1.71 V to 3.6 V | 1.71 V to 3.6 V | 1.71 V to 3.6 V |
| Interface | I2C / SPI | I2C / SPI | I2C / SPI | I2C / SPI | I2C / SPI | I2C / SPI |
주요 차별점
- True 9-axis single-package integration (vs LSM6DSLTR + LIS2MDLTR split)
- Wide gyroscope full-scale of ±2000 dps (vs ICM-42688-P)
- Dual independent I2C addresses (vs LSM6DS3TR)
설계 노트
Place a 100 nF X7R ceramic decoupling capacitor within 2 mm of the VDD pin and a 10 uF bulk capacitor on the same net. Per ST datasheet DM00103319, follow the recommended power-up sequence in Section 2.2.1: power VDD first, wait for the regulator rise time, then drive VDDIO. Driving VDDIO before VDD can latch the part. For battery applications, the device supports 1.9 V operation directly from a single-cell Li-ion after the protection FET.
Keep all ferromagnetic material (connector shells, inductors, FPC shields, mounting screws) at least 5 mm away from the package - the magnetometer's Hall-effect/MR element is sensitive to stray fields and will produce hard-iron distortion. Route the I2C bus away from switching DC-DC nodes; if unavoidable, use a guard trace tied to ground. Place the sensor at the geometric center of the host PCB when used for tilt/orientation to minimize lever-arm error.
Do not skip configuring the magnetometer's temperature-compensation registers - without it, heading drifts several degrees across a 20 C ambient swing. When using FIFO, set the watermark interrupt so the host wakes only when >= N samples are buffered; polling wastes power. Avoid VDDIO > VDD + 0.1 V; the absolute-maximum table in the datasheet shows this stresses the I/O ESD cells. For shutdown, drive CS high and clear CTRL_REG1/2/3 per the power-down sequence rather than cutting VDD abruptly.
규정 준수 정보
RoHS and REACH compliant per ST product page. Industrial grade only - not AEC-Q100 qualified; for automotive under-hood choose ASM330LHH. CMRT conflict-minerals declaration current.