ICM-42688-P - 6-Axis MEMS IMU with 2KB FIFO | TDK InvenSense
MPN: ICM-42688-P ✓ 啟用中ICM-42688-P 概覽
An IMU (Inertial Measurement Unit) is a sensor that measures angular rate and linear acceleration using gyroscopes and accelerometers. The ICM-42688-P combines these into a single package, providing high accuracy and low noise for motion tracking. IMUs are essential in applications requiring orientation and movement detection, such as flight controllers, wearable devices, and navigation systems. The ICM-42688-P is part of the broader category of motion sensors, which includes accelerometers, gyroscopes, and magnetometers, and is a key component in the sensor fusion hierarchy.
Key features include a gyroscope noise density of 2.8 mdps/√Hz, an accelerometer noise density of 70 µg/√Hz, and a programmable output data rate up to 32 kHz for the gyroscope and 32 kHz for the accelerometer. The device offers a 2 kB FIFO to reduce bus traffic and system power consumption, and supports a wide supply voltage range of 1.71 V to 3.6 V. It also includes programmable interrupts and a digital motion processor (DMP) for advanced motion processing.
The ICM-42688-P utilizes advanced MEMS technology with a low-power architecture, achieving a typical current consumption of 0.9 mA in low-noise mode and 0.45 mA in low-power mode. The device features a temperature range of -40°C to +85°C and is RoHS compliant. Its small footprint and low power make it ideal for battery-powered and space-constrained designs.
Typical applications include drone flight controllers, where the ICM-42688-P provides the low noise and high output rate required for stable flight; robotics, for precise motion control and orientation sensing; and AR/VR headsets, for accurate head tracking. The device is also used in industrial monitoring and wearable health devices.
When designing with the ICM-42688-P, ensure proper PCB layout with adequate decoupling capacitors on the power supply pins and careful routing of the I2C/SPI lines to minimize noise. The device supports both I2C and SPI, allowing flexibility in system integration.
直接替換替代品,適用於 ICM-42688-P — 相同封裝,腳位對腳位相容。需重新設計 PCB 的不同封裝零件不列入。
此系列的變體
與下列產品可直接替換的同系列型號: ICM-42688-P (相同外形與佔位) — 差異在於 Accelerometer Noise Density, Gyroscope Noise Density, Interface, Package.
BMI270
聯絡詢價
查看資料表 →BMI088
聯絡詢價
查看資料表 →LSM6DS3TR-C
聯絡詢價
查看資料表 →ICM-42688-V
📋 參考替代品(不在目錄中)
ICM-42688-PC
📋 參考替代品(不在目錄中)
ISM330DHCX
📋 參考替代品(不在目錄中)
ICM-42688-P 最大額定值與電氣特性
| 感測器類型 | Accelerometer, Gyroscope, 6 Axis |
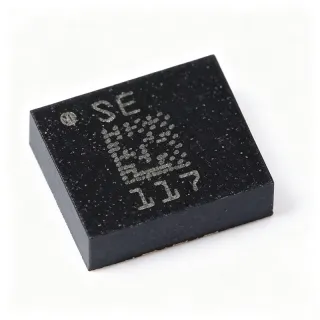
| 封裝 | 14-pin LGA, 2.5 x 3.0 x 0.91 mm |
| 介面 | I2C, SPI, I3C |
| Gyroscope Full Scale Range | ±15.5 dps to ±2000 dps |
| Accelerometer Full Scale Range | ±2 g to ±16 g |
| Gyroscope Noise Density | 2.8 mdps/√Hz |
| Accelerometer Noise Density | 70 µg/√Hz |
| Output Data Rate (Gyro) | Up to 32 kHz |
| Output Data Rate (Accel) | Up to 32 kHz |
| FIFO Size | 2 kB |
| 供應電壓 | 1.71 V to 3.6 V |
| Current Consumption (Low-Noise Mode) | 0.9 mA |
| Current Consumption (Low-Power Mode) | 0.45 mA |
| 工作溫度 | -40°C to +85°C |
| RoHS | Compliant |
ICM-42688-P 腳位配置
| 腳位 1 | VDD — Power supply (1.71V to 3.6V) |
| 腳位 2 | GND — Ground |
| 腳位 3 | SCL/SPC — I2C clock or SPI clock |
| 腳位 4 | SDA/SDI — I2C data or SPI data in |
| 腳位 5 | ADO/SDO — I2C address select or SPI data out |
| 腳位 6 | CS — Chip select (active low) |
| 腳位 7 | INT1 — Interrupt 1 |
| 腳位 8 | INT2 — Interrupt 2 |
| 腳位 9 | RESV — Reserved, connect to GND |
| 腳位 10 | VDDIO — I/O supply voltage |
| 腳位 11 | GND — Ground |
| 腳位 12 | GND — Ground |
| 腳位 13 | GND — Ground |
| 腳位 14 | GND — Ground |
典型應用
ICM-42688-P 適用於 6 應用s: Drone Flight Controllers, Robotics, AR/VR Headsets, Industrial Monitoring, Wearable Health Devices, Navigation Systems.
Drone Flight Controllers
The ICM-42688-P is ideal for drone flight controllers due to its low noise density (2.8 mdps/√Hz gyro) and high output data rate (up to 32 kHz), which enable precise attitude estimation and stable flight. Its 2 kB FIFO reduces bus traffic, allowing the flight controller to read sensor data efficiently. The device's small 2.5 x 3.0 mm package fits compact drone designs, and its low power consumption (0.9 mA) extends battery life. According to a 2026 UAV model blog, the ICM-42688-P is the preferred gyro for Betaflight 4.5+ builds.
推薦
Robotics
In robotics, the ICM-42688-P provides precise motion sensing for orientation and movement control. Its low noise and high ODR enable accurate feedback for balance and navigation algorithms. The device's ultralow-power wake-on-motion feature allows the robot to remain in a low-power state until movement is detected, conserving battery life. The 2 kB FIFO helps manage sensor data efficiently, reducing processor load. The ICM-42688-P's wide supply voltage range (1.71 V to 3.6 V) makes it compatible with various robot power systems.
推薦
AR/VR Headsets
The ICM-42688-P is well-suited for AR/VR headsets, where accurate head tracking is critical. Its low noise density and high ODR (up to 32 kHz) enable smooth and responsive motion tracking, reducing motion sickness. The device's small package and low power consumption are ideal for wearable devices. The 2 kB FIFO allows efficient data transfer to the host processor, minimizing latency. According to the TDK datasheet, the ICM-42688-P is designed for high-performance motion tracking in consumer electronics.
推薦
Industrial Monitoring
For industrial monitoring, the ICM-42688-P provides reliable vibration and motion sensing for predictive maintenance and equipment health monitoring. Its wide temperature range (-40°C to +85°C) and low noise ensure accurate measurements in harsh environments. The device's programmable interrupts can trigger alerts on threshold crossings, reducing the need for continuous polling. The 2 kB FIFO helps manage data bursts, and the I2C/SPI interfaces allow easy integration with industrial controllers.
推薦
Wearable Health Devices
The ICM-42688-P is suitable for wearable health devices, such as fitness trackers and smartwatches, due to its low power consumption (0.45 mA in low-power mode) and small footprint. It can detect motion and orientation for activity tracking and fall detection. The ultralow-power wake-on-motion feature allows the device to remain in a low-power state until movement is detected, extending battery life. The 2 kB FIFO reduces the frequency of host processor wake-ups, further saving power.
推薦
Navigation Systems
In navigation systems, the ICM-42688-P provides inertial sensing for dead reckoning and sensor fusion with GPS. Its low noise and high ODR enable accurate velocity and position estimation. The device's 2 kB FIFO allows efficient data collection, and its programmable interrupts can synchronize with external sensors. The wide supply voltage range and low power consumption make it suitable for portable navigation devices. According to the TDK datasheet, the ICM-42688-P is designed for high-performance motion tracking.
推薦
推薦產品摘要
工程參考資料,適用於 ICM-42688-P — 比較、設計指引及合規資訊。
選型指南
與替代品比較
| 參數 | 本產品 | ICM-42688-V | ICM-42688-PC | BMI270 | BMI088 | LSM6DS3TR-C | ISM330DHCX |
|---|---|---|---|---|---|---|---|
| Package | 14-pin LGA | 14-pin LGA | 14-pin LGA | 14-pin LGA | 16-pin LGA | 14-pin LGA | 14-pin LGA |
| Brand | TDK InvenSense | TDK InvenSense | Tokmas | Bosch | Bosch | STMicroelectronics | STMicroelectronics |
主要差異化特點
- Lower gyroscope noise density (對比BMI270)
- Higher output data rate (對比BMI270)
- I3C interface support (對比LSM6DS3TR-C)
設計說明
Place decoupling capacitors (100 nF and 1 µF) close to the VDD and VDDIO pins to ensure stable power supply. Use a solid ground plane under the sensor to minimize noise. Route I2C/SPI lines with controlled impedance and keep them short to reduce signal integrity issues. According to the TDK datasheet, proper layout is critical for achieving the specified noise performance.
The ICM-42688-P operates from 1.71V to 3.6V. Ensure the supply voltage is within this range and that VDDIO is set to the appropriate level for the host interface. In low-power mode, the device consumes 0.45 mA, but during startup or high ODR operation, current can spike. Use a low-dropout regulator with adequate headroom to maintain stable voltage.
Avoid placing the sensor near heat sources or high-frequency components that can cause thermal drift or electrical noise. The ICM-42688-P is temperature sensitive and can drift if not properly isolated. Also, ensure the I2C address is correctly configured via the ADO pin to avoid address conflicts. According to SlimeVR docs, the ICM-42688 is temperature sensitive and drifts quickly, so thermal management is essential.
合規資訊
RoHS compliant per TDK datasheet. Other compliance info not specified in provided data.